Drone-Based Active Laser Reflection Countermeasure System: Design and Implementation Framework
I. System Architecture and Operational Concept
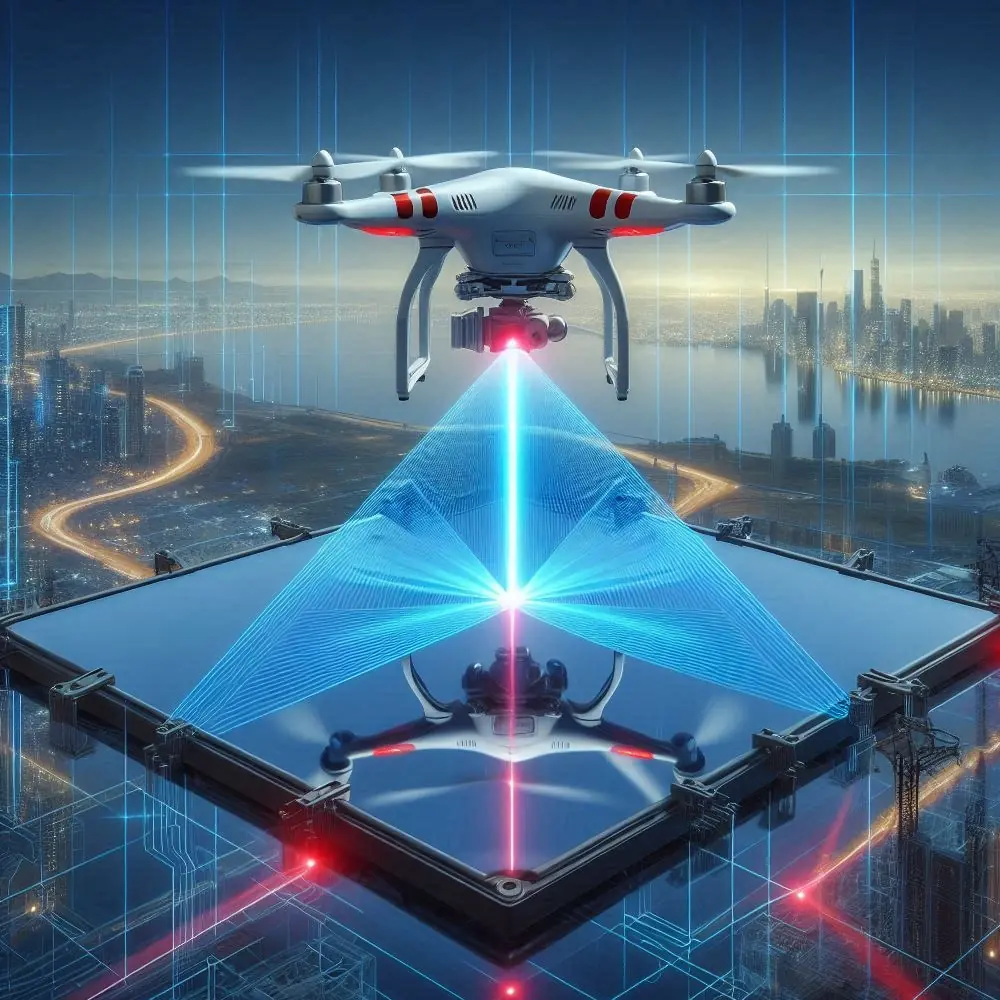
The proliferation of High-Energy Laser (HEL) weapon systems presents a significant and evolving threat to Unmanned Aerial Vehicles (UAVs) across various operational domains. This report outlines the design and implementation framework for a drone-based active laser countermeasure system. The system is designed to detect an incoming HEL attack, rapidly reorient the UAV, deploy specialized reflective surfaces, and direct the hostile laser energy back towards its source, thereby neutralizing the threat.
A. Threat Definition: High-Energy Laser (HEL) Weapons Against UAVs
HEL weapons are increasingly being developed and deployed as a means to counter UAVs, owing to their speed-of-light engagement, precision, and potential for causing effects ranging from sensor dazzling to catastrophic structural failure.1 These weapons can be ground-based, ship-borne 3, or potentially airborne, creating a multi-domain threat environment. The primary concern is laser-induced damage, which can manifest as temporary or permanent impairment of optical sensors 1, degradation of critical components, or complete destruction of the airframe.3
The operational environment necessitates an assumption that the drone will face sophisticated adversaries. HEL systems are not merely static beams but are often integrated into comprehensive Laser Weapon Systems (LWS) incorporating advanced tracking and targeting capabilities.3 These LWS may utilize radar for initial detection, infrared (IR) sensors for tracking, and HEL telescopes equipped with fast-steering mirrors to maintain a lock on the target.3 Consequently, the drone's countermeasure strategy must be executed with extreme rapidity, ideally before the attacking LWS can significantly adjust its aim or predict the drone's defensive posture. The speed-of-light nature of laser attacks mandates an autonomous and rapid response capability.3
A critical factor in laser weapon effectiveness is the "dwell time"—the duration for which the laser beam must remain focused on a specific point on the target to impart sufficient energy to cause damage.3 For instance, some systems may require several seconds of continuous lasing to neutralize a UAV.4 The proposed countermeasure system is predicated on interrupting this dwell time decisively and turning the threat back upon the attacker. The efficacy of the countermeasure is therefore directly tied to its ability to react well within this damaging dwell window, minimizing energy absorption by the drone and maximizing the disruptive effect on the HEL source.
B. Countermeasure Principle: Detect, Turn, Deploy, Reflect (DTDR)
The core operational concept of the proposed system is the Detect, Turn, Deploy, Reflect (DTDR) sequence. This sequence is initiated upon confirmation of a hostile laser engagement and comprises four critical phases:
-
Detect: The onboard Laser Warning Receiver (LWR) subsystem continuously monitors the environment for laser emissions. Upon detecting an incident laser beam, the LWR analyzes its characteristics (wavelength, intensity, pulse parameters) to confirm it as a high-power threat, distinguishing it from benign sources such as friendly rangefinders or ambient light. A crucial part of this phase is "hit confirmation"—verifying that the laser is indeed impinging on the UAV.
-
Turn: Once a credible threat is confirmed and its Angle of Arrival (AoA) determined, the UAV's flight control system executes a rapid reorientation maneuver. This typically involves a 180-degree yaw rotation to align the drone's designated reflective surfaces towards the incoming laser's AoA.
-
Deploy: Concurrently with or immediately following the turn maneuver, specialized high-reflectivity mirrors stowed on the sides of the UAV are rapidly deployed to their operational positions.
-
Reflect: With the mirrors deployed and the UAV oriented towards the threat, the system utilizes these surfaces to reflect the incident HEL beam back towards its origin. Fine-tuning of the reflected beam's direction may be accomplished using integrated Fast Steering Mirrors (FSMs) to ensure precision aiming at the laser source.
The entire DTDR sequence must be executed within an extremely constrained timeframe, ideally in the order of tens to a few hundred milliseconds, to effectively counter the HEL threat. This operational imperative underscores the need for precise and rapid synchronization of all constituent subsystems: the LWR, the flight controller, the mirror deployment actuators, and any FSMs employed for fine aiming. Any significant latency or error within one component can compromise the entire countermeasure. The successful execution of the DTDR sequence transforms the UAV from a passive target into an active countermeasure platform, aiming not merely for survival through passive protection (such as reflective coatings 4), but for the active neutralization of the HEL source by potentially damaging or dazzling its optical systems.
C. Key Performance Parameters (KPPs) and System-Level Requirements
The effectiveness of the DTDR system is defined by a set of Key Performance Parameters (KPPs) that dictate the design requirements for each subsystem. These KPPs are highly interdependent, necessitating a holistic approach to system design where trade-offs are carefully managed. For example, enhancing reorientation agility might impose constraints on payload capacity for mirrors or LWRs, or increase power consumption.
The principal KPPs for the DTDR system include:
-
Overall Reaction Time: The total time elapsed from confirmed laser hit detection to the initiation of effective reflection back to the source. Target: < 200 milliseconds, with an ideal goal of < 100 milliseconds.
-
Detection Probability (Pd) and False Alarm Rate (FAR): The LWR must exhibit a high Pd for genuine HEL threats while maintaining an extremely low FAR to prevent unnecessary execution of aggressive and energy-intensive counter-maneuvers.
-
Reorientation Agility: The time required to complete the 180° yaw maneuver. Target: < 1-2 seconds, contingent upon achieving specific maximum angular acceleration and angular rate capabilities.
-
Mirror Deployment Speed: The time interval from the deployment command to the mirrors being fully deployed and securely locked in their operational orientation. Target: < 50 milliseconds, ideally < 20 milliseconds.
-
Reflection Accuracy: The pointing accuracy of the reflected HEL beam back towards the source. Target: Sub-milliradian accuracy, accounting for all cumulative error sources in the pointing chain.
-
Mirror Reflectivity and Laser-Induced Damage Threshold (LIDT): Mirrors must exhibit very high reflectivity (ideally >99%) at the anticipated threat laser wavelengths and possess a high LIDT to survive the incident laser energy during the engagement period.
-
Size, Weight, Power, and Cost (SWaP-C): All subsystems must adhere to the constraints imposed by UAV platform integration, including limitations on physical dimensions, mass, power consumption, and overall system cost.
-
Operational Range: The effective distance at which the countermeasure can successfully engage and neutralize an HEL threat. This is influenced by factors such as LWR sensitivity, reflection accuracy, and atmospheric conditions.
A summary of these system-level KPPs is presented in Table I.C.1. This table serves as a foundational reference for guiding the design and development of the individual subsystems, ensuring that all engineering efforts are aligned with the primary objectives of speed, precision, and effectiveness.
| KPP | Target Value | Rationale/Criticality | Key Subsystems Involved |
|---|---|---|---|
| Overall Reaction Time | < 200 ms (ideal < 100 ms) | Crucial for interrupting laser dwell time before damage occurs. | LWR, AI Processor, Flight Controller, Mirror Actuators, FSM |
| Detection Probability | > 99% for defined threats | High confidence in detecting actual attacks. | LWR, AI Processor |
| False Alarm Rate | < 10−6 (representative) | Prevent unnecessary, potentially mission-compromising maneuvers. | LWR, AI Processor, Hit Confirmation Sensors |
| 180° Yaw Time | < 1.5 s | Rapid reorientation is key to timely reflection. | UAV Platform (Motors, Airframe), Flight Controller |
| Mirror Deployment Speed | < 50 ms (ideal < 20 ms) | Mirrors must be in place quickly after/during turn. | Deployment Mechanism, Actuators |
| Reflection Accuracy | < 0.5 mrad (goal < 0.1 mrad) | Essential for hitting the laser source aperture at range. | FSM, LWR (AoA), Flight Controller, Mirror Stability |
| Mirror Reflectivity | > 99% at threat wavelengths | Maximize reflected energy, minimize mirror heating. | Mirror Coating |
| Mirror LIDT | Sufficient for expected threat fluence/intensity | Mirror must survive the incident laser pulse during reaction. | Mirror Substrate & Coating |
| System Weight (Payload) | < 5 kg (example, platform dependent) | Minimize impact on UAV endurance and agility. | All Subsystems |
| System Power | < 100 W avg (example, platform dependent) | Minimize impact on UAV power budget. | All Subsystems, especially Processors, Actuators |
II. Laser Threat Detection and Characterization Subsystem
The Laser Warning Receiver (LWR) subsystem is the vanguard of the DTDR system, tasked with the initial detection of laser illumination, comprehensive characterization of the incident beam, confirmation of a direct hit, and generation of the trigger signal for the subsequent countermeasure sequence. Its performance in terms of speed, accuracy, and reliability is fundamental to the overall efficacy of the active protection system.
A. Laser Warning Receiver (LWR) Design and Sensor Integration
The LWR must provide real-time data on the Angle of Arrival (AoA), wavelength, intensity, and pulse characteristics of incident laser radiation.2 This necessitates a carefully designed sensor suite and associated processing capabilities.
1. Photodetector Selection:
A multifaceted photodetector strategy is likely required to achieve broad spectral coverage (e.g., from Ultraviolet (UV) at 220 nm to Short-Wave Infrared (SWIR) at 1700 nm or beyond 9) and a wide dynamic range capable of handling both faint scattered signals and high-intensity direct illumination.
-
Avalanche Photodiodes (APDs): Due to their internal gain mechanism, APDs are highly sensitive and well-suited for detecting weak laser signals. Silicon (Si) APDs typically cover the spectral range from UV to Near-Infrared (NIR), approximately 250 nm to 1100 nm, while Indium Gallium Arsenide (InGaAs) APDs extend detection into the NIR/SWIR range from 1100 nm to 1700 nm.10 Their application in laser rangefinding and LiDAR systems underscores their capability to detect pulsed laser emissions.6
-
PIN Photodiodes: These can also be employed, often selected for applications requiring response to higher optical powers or for specific response time characteristics not met by APDs.10
-
Imaging Sensors (CMOS/CCD): Imaging-type LWRs can utilize Complementary Metal-Oxide-Semiconductor (CMOS) or Charge-Coupled Device (CCD) area arrays. An optical system focuses the incident laser onto the sensor plane, and the location of the resultant spot provides AoA information, while analysis of the spot can yield other spatial characteristics.7 The advent of high-speed CMOS image sensors, with frame rates reaching millions of frames per second (Mfps) 11, opens possibilities for temporal analysis of the laser spot itself, potentially extracting pulse information directly from image sequences.12
-
Thermal Sensors for Hit Confirmation: While thermal cameras are commonly used for detecting the heat signature of drones themselves 13, they also offer a viable method for confirming a direct HEL impact. A high-power laser striking the UAV's skin will cause a rapid and localized temperature increase. Simple, wide Field of View (FoV) thermal sensors, such as low-cost FLIR Lepton microbolometers 13 or more sophisticated Mid-Wavelength Infrared (MWIR) sensors 3, could be arrayed on the UAV's exterior or strategically placed to detect this thermal spike.
The choice of photodetector wavelength coverage must be aligned with anticipated HEL threats. Common military lasers operate within specific spectral bands, such as 1.06 µm (Nd:YAG), 1.54 µm (eye-safe), and 10.6 µm (CO2).7 Modern LWRs often employ multi-channel detectors or detector arrays with distinct spectral filters to monitor several laser wavelengths simultaneously, ensuring comprehensive threat coverage.2 This approach, while increasing complexity and SWaP, is essential for defending against a diverse range of laser threats.
A critical aspect of the detection phase is robust "hit confirmation." Relying solely on the optical detection of a laser beam might lead to an unacceptable FAR due to reflections from other surfaces or illumination by non-threatening laser sources. To mitigate this, the system should correlate the primary LWR optical detection with a secondary physical effect indicative of a direct impact. For example, the sudden dazzling or saturation of the drone's own operational cameras, as detailed in studies on laser dazzling effects 1, occurring concurrently with an LWR alert, would strongly suggest a direct hit. Alternatively, a rapid, localized temperature increase detected by an array of simple thermal sensors on the UAV's fuselage, spatially correlated with the AoA reported by the LWR, could serve as definitive hit confirmation. This multi-modal approach to hit confirmation is crucial for ensuring that the highly dynamic and energy-intensive countermeasure sequence is initiated only in response to a genuine attack.
2. Angle of Arrival (AoA), Wavelength, and Intensity Measurement Techniques:
-
Angle of Arrival (AoA) Determination:
-
Segmented Detectors/Multiple Optical Channels: One common approach involves using an array of photodetectors, each covering a specific angular sector. The D5™ system, for instance, utilizes two units, each with two sensors, to provide AoA information segmented in the azimuth direction over a 200° horizontal FoV.15 More complex systems, such as that described in U.S. Patent 7,683,310, envision hundreds of individual optical channels, each with optical wedges and lenses focusing light onto multi-wavelength photodetectors. This design allows for simultaneous AoA and wavelength determination.16 Commercial modules like the Excelitas EXACTD series employ Gray-coded photodiode arrays to encode the AoA with resolutions ranging from ±6.0° down to ±0.8°.9
-
Cylindrical Lens and Linear Array with Gaussian Fitting: This technique involves focusing the incoming laser radiation using a plano-convex cylindrical lens onto a linear array of photodetectors. The AoA is calculated by determining the displacement of the centroid of the focused Gaussian beam profile on this array. High angular resolution, on the order of 0.105°, has been reported for such systems, with the precision dependent on the number of sampling points (detectors) and the curve-fitting algorithm used.18
-
Imaging Systems (CCD/CMOS): In these LWRs, a wide-angle objective lens or a fisheye lens projects an image of the surrounding environment onto a 2D planar array detector (CCD or CMOS). An incident laser beam appears as a bright spot on this array, and the coordinates of this spot directly correspond to the AoA.7 The angular resolution is a function of the lens's FoV and the pixel density of the image sensor. A hierarchical AoA determination strategy may offer an optimal balance between speed and precision. Fast, moderate-resolution AoA data from segmented detectors (similar to the D5 system 15) could provide an initial cue to trigger the drone's rapid turn maneuver. Subsequently, a more precise (though potentially slower) AoA measurement from a cylindrical lens system, an imaging LWR, or refinement via an FSM's tracking sensor could provide the high-fidelity pointing information necessary for accurate retro-reflection. This balances the immediate need for a reactive maneuver with the ultimate requirement for precise aiming. Furthermore, the ability of some LWRs to detect atmospherically scattered laser light 19 could provide an earlier warning or detection capability even if the main beam does not directly impinge on a primary sensor. However, it must be recognized that atmospheric effects also introduce signal degradation and pointing errors for both the incoming threat and the outgoing countermeasure beam.20
-
-
Wavelength Determination:
-
Multi-Dielectric Stack Photodetectors: As proposed in U.S. Patent 7,683,310, specialized photodetectors can be fabricated with multiple semiconductor layers within a dielectric stack. These layers are designed to selectively absorb and generate a signal based on the wavelength of the incident light, allowing for wavelength determination from the detector's electrical output.16
-
Filtered Detector Arrays: A common technique involves using an array of photodetectors, each paired with a distinct narrowband optical filter. The wavelength of the incident laser is identified by determining which filtered detector registers the strongest signal.7
-
Miniature Spectrometers: While potentially offering high wavelength resolution, integrated spectrometers 8 might introduce undesirable latency or increase the SWaP budget compared to filter-based or specialized detector approaches.
-
-
Intensity Measurement:
-
Photodetectors inherently produce an output signal (current or voltage) proportional to the incident optical power.25 A key challenge for LWRs facing HEL threats is the extremely wide dynamic range required. The system must be sensitive enough to detect faint, scattered laser light for early warning or operation in adverse conditions, yet robust enough to measure the intensity of a direct HEL impact without saturating or being damaged. This can be achieved using multiple gain stages in the amplification circuitry, employing detectors with different intrinsic sensitivities (e.g., the low- and high-sensitivity channels in Excelitas EXACTD modules 9), or implementing advanced techniques like event-based time-to-digital converters (TDCs) and time-domain compensation, which have demonstrated dynamic ranges exceeding 1:250,000 in laser radar applications.26
-
3. Hit Detection and Confirmation Mechanisms:
As previously noted (Insight II.A.1.1), robust hit confirmation is vital. This involves the intelligent fusion of data from the primary LWR optical sensors with secondary physical indicators of a direct laser impact:
-
Thermal Signature Analysis: Deploying an array of simple thermal sensors (e.g., microbolometers) across the UAV's skin to detect the characteristic rapid, localized temperature rise at the point of laser impingement. Data from low-cost thermal cameras like the FLIR Lepton 13 or more advanced MWIR sensors 3 can be processed to identify such thermal transients.
-
Optical Sensor Dazzling/Damage Monitoring: Continuously monitoring the output of the UAV's own optical systems (e.g., navigation cameras, electro-optical/infrared (EO/IR) payload sensors) for signatures consistent with laser dazzling. These effects can include pixel saturation, blooming, streaking, or complete image blackout, as documented in research on laser effects on cameras.1
-
Acoustic Signature Detection: While primarily used for detecting the acoustic signature of UAVs themselves 13, it is conceivable that a high-power laser impact, particularly from a pulsed HEL, could generate a detectable acoustic shockwave or a characteristic sound from material interaction. This remains a more speculative method based on available information.
The logic for fusing these multi-modal sensor inputs for hit confirmation must be computationally efficient and highly reliable to make a definitive "hit" decision within the stringent overall reaction time budget of the DTDR sequence, minimizing both delays and the probability of false counter-deployments. A false positive triggering a violent 180-degree turn and mirror deployment could be detrimental to the drone's mission or flight stability.
| Sensor Type | Detected Parameter(s) | Pros | Cons | Typical Response Time | AoA Accuracy | Key Sources |
|---|---|---|---|---|---|---|
| Segmented Photodiodes | AoA (coarse), Intensity | Fast response (<50 ms for D5 15), relatively simple, good FoV | Lower AoA resolution, wavelength ambiguity without filters | < 50 ms | Segmented (e.g., ±22.5° per segment) or ±0.8° to ±6° (EXACTD 9) | 9 |
| Cylindrical Lens + Array | AoA (high-res), Intensity | High angular resolution (e.g., 0.105° 18), good for precise AoA | More complex processing (Gaussian fitting), potentially larger | ms to 10s of ms | ~0.1° - 1° | 18 |
| Imaging (CCD/CMOS) | AoA (high-res), Spot Characteristics, (potentially pulse timing with high-speed sensors) | High AoA resolution, potential for spatial/temporal analysis of spot | Higher processing load, frame rate limits temporal resolution | Frame rate dependent (e.g., 10s of ms for standard, µs for ultra-high speed 11) | < 0.1° (depends on optics/pixels) | 7 |
| APD Arrays | Intensity, (Wavelength with filters/stacks), (AoA with segmentation) | High sensitivity, fast response, good for pulsed lasers | Requires high voltage, can be complex, temperature sensitive | ns to µs | N/A (detector specific) | 6 |
| Multi-Dielectric Stack Photodetectors | Wavelength, Intensity, AoA (if arrayed/segmented) | Integrated wavelength/AoA determination | Complex fabrication, potentially limited spectral bands per device | Likely fast (ns-µs) | Design dependent | 16 |
| Microbolometer Array (Thermal) | Temperature (Hit Confirmation) | Direct hit confirmation, passive | Slower response than photodetectors, detects heat not light directly | 10s of ms to 100s of ms | N/A (detects impact location) | 13 |
B. Advanced Signal Processing for Laser Signature Analysis
Beyond simple detection, the LWR subsystem must perform sophisticated signal processing to extract detailed characteristics from the detected laser signal. This information is crucial for accurately classifying the threat (e.g., distinguishing a low-power rangefinder from a high-power weaponized laser, or identifying specific laser weapon system signatures) and informing the subsequent countermeasure response.2
1. Extraction of Pulse Parameters (PRF, Pulse Width, Jitter, PIM Codes):
Many military and commercial HEL systems utilize pulsed operation. The temporal characteristics of these pulses form a critical part of their signature.
-
Pulse Repetition Frequency (PRF) and Pulse Width (Duration): These are fundamental parameters. PRFs can vary from a few Hertz to many Megahertz 27, while pulse widths can range from nanoseconds 29 for Q-switched or mode-locked lasers, to milliseconds for long-pulse lasers, or even continuous wave (CW) operation.30 Real-time analysis of these parameters is essential for threat identification.31 The Leonardo RALM02/V2 LWR, for example, detects pulsed wave laser radiation and measures its characteristics for comparison against an internal threat database.33
-
Pulse Interval Modulation (PIM) and Other Pulse Coding: To enhance guidance accuracy, provide identification, or improve resistance to countermeasures, laser systems may employ coded pulse sequences. Techniques such as Pulse Interval Modulation (PIM), or more complex schemes analogous to Optical Code Division Multiple Access (OCDMA) where specific pulse patterns are used 34, can create unique signatures. The LWR's signal processing unit must be capable of recognizing or decoding these patterns to accurately identify the laser source or its intent.
-
PRF Jitter and Staggered PRF: Sophisticated laser threats may employ PRF jitter (intentional, small variations in pulse timing) or staggered PRFs (cycling through a sequence of different PRFs) to make detection and analysis by simpler LWRs more difficult.35 The signal processing algorithms within the DTDR system's LWR must be robust enough to handle such agile pulse trains and correctly determine the underlying PRF patterns or identify the staggering sequence.
-
Pulse Amplitude/Energy: Measuring the peak power or energy of individual pulses is critical for assessing the threat level.25 This helps in differentiating between, for example, a low-energy laser rangefinder and a high-energy pulsed weapon.
-
Pulse Shape (Rise Time, Fall Time): The specific shape of a laser pulse, characterized by its rise time and fall time, can also serve as a distinguishing feature for certain laser types.37
The temporal resolution of the entire detection and processing chain, from the photodetector through the analog-to-digital converter (ADC) to the digital signal processor, must be adequate for the shortest pulse widths and highest PRFs anticipated. For instance, to accurately characterize a laser with 10-nanosecond pulses, the photodetector must have a rise/fall time significantly shorter than this, and the ADC sampling rate would need to be in the Giga-samples per second (GSPS) range to capture the pulse waveform with fidelity. This has substantial implications for component selection, data throughput, and onboard processing power.
A core function of the advanced signal processing unit is to match the extracted laser signature (a multi-parameter vector including AoA, wavelength, intensity, and various pulse characteristics) against an onboard threat signature library.4 This library contains the known parameters of various friendly, neutral, and hostile laser systems. The fidelity of this library and the speed and accuracy of the matching algorithm are critical for correct threat declaration.
2. Deinterleaving of Complex/Multiple Pulse Trains:
In a complex electromagnetic environment, the LWR may simultaneously receive pulses from multiple laser sources (e.g., friendly designators, multiple hostile systems, environmental reflections). Deinterleaving algorithms are essential to sort these jumbled pulses into distinct, coherent pulse trains, each attributable to a unique emitter.33 This process typically involves clustering pulses based on parameters such as AoA, PRF, pulse width, and wavelength. While specific laser deinterleaving algorithms are not extensively detailed in the provided materials (radar systems heavily use such techniques for PRF analysis 35, and similar principles can be adapted), this capability is crucial for avoiding threat misidentification and ensuring the countermeasure is directed against the correct source. The lack of detailed public information on specific laser deinterleaving techniques suggests this is a sophisticated and often proprietary aspect of advanced LWR design, likely requiring significant research and development or the procurement of specialized, military-grade processing modules.
| Parameter | Measurement Technique/Sensor | Typical Values for Threat Types (LRF, LTD, HEL, Dazzler) | Significance in Threat Library | Relevant Sources |
|---|---|---|---|---|
| PRF | High-speed photodetector + Counter/Timer or FFT of pulse train | LRF: low Hz to kHz; LTD: coded, often 10s of Hz; HEL (pulsed): Hz to MHz; Dazzlers: variable, can be CW or pulsed. | Primary identifier, distinguishes continuous from pulsed, helps classify weapon type. Staggered/agile PRFs indicate advanced threats. | 27 |
| Pulse Width (Duration) | High-speed photodetector + Oscilloscope-like analysis (ADC+DSP) | LRF/LTD: ns to µs; HEL (pulsed): fs to ms; Dazzlers: variable, ns to CW. | Differentiates short-pulse (e.g., Q-switched) from long-pulse or CW lasers. Critical for energy calculation and LIDT assessment. | 27 |
| Pulse Energy/Peak Power | Calibrated photodetector + Integrator/Peak Detector | LRF: mJ; LTD: 10s-100s mJ; HEL: J to kJ (pulsed), kW to MW (CW); Dazzlers: µJ to mJ (pulsed), mW to W (CW). | Direct indicator of damage potential. Essential for threat prioritization. | 25 |
| Wavelength | Filtered detectors, Spectrometer, Multi-dielectric stack detector | Common: 532nm, 8xxnm, 9xxnm, 1064nm, 1550nm, 10.6µm. Specific military lasers have defined wavelengths. | Crucial for identifying laser type (e.g., Nd:YAG, Fiber, CO2) and selecting appropriate mirror coating. Helps defeat wavelength-specific countermeasures. | 7 |
| Angle of Arrival (AoA) | Segmented detectors, Imaging sensors, Cylindrical lens array | N/A (direction to threat) | Determines direction for UAV reorientation and reflection. Multiple simultaneous AoAs indicate multiple sources needing deinterleaving. | 9 |
| PIM Code / Pulse Pattern | DSP analysis of pulse arrival times | Specific coded sequences for LTDs (e.g., per STANAG 3733). HELs may use simpler or no coding. | Identifies specific weapon systems (friend or foe), confirms guidance signals. Essential for avoiding fratricide and engaging correct threat. | 14 |
| Rise/Fall Time | Very high-speed photodetector + ADC + DSP | ns for fast Q-switched pulses. | Can provide additional signature information for specific laser technologies. | 37 |
| PRF Jitter/Stagger | Statistical analysis of Pulse Repetition Intervals (PRIs) | Deliberate variations in PRI or cycling through PRFs. | Indicates advanced threat attempting to evade simple PRF-based detection. Requires more sophisticated tracking algorithms. | 35 |
C. AI-Driven Real-Time Threat Classification and Decision Making
Artificial Intelligence (AI) and Machine Learning (ML) offer powerful tools to augment the capabilities of the LWR subsystem, enabling more accurate threat classification, adaptation to novel or evolving laser signatures, and faster decision-making for countermeasure deployment.2
AI for Threat Signature Recognition:
ML algorithms can be trained on extensive datasets of laser signatures, which include the parameters extracted in the previous signal processing stage (e.g., AoA, wavelength, intensity, PRF, pulse width, PIM codes).
-
Supervised Learning Models:
-
Support Vector Machines (SVMs) and Random Forests (RF) are effective for classification tasks, particularly when dealing with well-defined feature sets, and can offer a degree of interpretability.41
-
Neural Networks (NNs):
-
Convolutional Neural Networks (CNNs) are well-suited for processing data with spatial structures, such as the output of imaging LWRs (analyzing the laser spot image) or spectrogram representations of pulse trains.44
-
Recurrent Neural Networks (RNNs), especially Long Short-Term Memory (LSTM) variants, excel at analyzing sequential data, making them ideal for classifying laser pulse trains based on their temporal patterns and inter-pulse relationships.42
-
Transformer Models: These are increasingly used for tasks involving long-range dependencies in sequential data and could be applied to analyze complex laser pulse sequences or evolving threat behaviors.42
-
-
Adaptive Threat Libraries and Novelty Detection:
A significant advantage of AI is its potential to identify and adapt to new laser threats not present in the pre-programmed signature library.2
-
Unsupervised Learning Models: Techniques such as autoencoders or isolation forests can be employed for anomaly detection. These models learn the characteristics of "normal" or known laser signals and can then flag incoming signals that deviate significantly as potential novel threats.42 This capability is crucial in a rapidly evolving threat landscape.
Real-Time Decision Making:
Upon high-confidence classification of an incident laser as a definite HEL threat (e.g., parameters matching a known hostile weapon system or a high-danger anomalous signature), the AI-driven decision engine can autonomously initiate the DTDR countermeasure sequence. This demands extremely low-latency inference capabilities, typically achieved by deploying optimized AI models on specialized embedded hardware.47 Modern UAVs are increasingly incorporating compact, powerful chips with embedded software for such AI-driven functionalities.47
Data Fusion:
AI algorithms can effectively fuse data from multiple sensor modalities within the LWR and hit confirmation subsystems (e.g., optical channel data, thermal sensor readings, UAV camera dazzling status). This fusion process can significantly improve classification accuracy, reduce the FAR, and provide a more robust overall threat assessment.43
The application of AI in this context is not merely for classifying a signal as "laser" or "not laser." It extends to a more nuanced situational awareness, such as distinguishing between a scanning laser rangefinder (lower immediate threat) and a laser target designator locked onto the UAV (higher immediate threat), based on subtle differences in their operational signatures.2 This allows for a more graduated and appropriate response. However, the "black box" nature of some complex AI models, like deep neural networks, can be a concern in safety-critical defense applications. Ensuring the reliability and trustworthiness of AI-driven decisions is paramount. Techniques from Explainable AI (XAI) might be necessary to provide insight into the AI's decision-making process, particularly if an incorrect classification could lead to catastrophic failure or fratricide.41 While Large Language Models (LLMs) are showing promise in broader cybersecurity applications such as DDoS attack detection or vulnerability analysis 40, their direct application to real-time, low-level signal classification on resource-constrained UAV hardware for LWRs is not yet evident from current research and would face substantial challenges regarding latency, model size, and the nature of the input data (highly structured sensor readings versus natural language or code). Established ML/DL models (SVMs, NNs) and specialized signal processing neural networks are likely more mature and suitable for this specific task.43
| AI/ML Model | Input Data Type | Strengths for LWR Application | Weaknesses/Limitations | Suitability for Real-Time Embedded Use | Key Sources |
|---|---|---|---|---|---|
| SVM / Random Forest | Extracted Pulse Parameters (PRF, PW, Energy, AoA, etc.) | Good with high-dimensional feature spaces, relatively interpretable, robust to overfitting with smaller datasets. | May require careful feature engineering, less effective with raw/unstructured sequential data. | High | 41 |
| CNN | Imaging LWR data (spot image), Spectrograms of pulse trains | Excellent for spatial feature extraction, automatic feature learning. | Requires significant labeled data, can be computationally intensive for complex architectures. | Moderate to High (with optimization) | 44 |
| RNN / LSTM | Raw pulse time series, Sequences of extracted parameters | Captures temporal dependencies and patterns in pulse trains, good for sequential data. | Can be complex to train, vanishing/exploding gradient issues (though LSTM mitigates this). | Moderate to High (with optimization) | 42 |
| Transformer | Long sequences of pulse data or parameters | Handles long-range dependencies effectively, parallelizable training. | Requires large datasets, computationally intensive, newer for signal processing tasks. | Moderate (emerging for embedded) | 42 |
| Autoencoder | Extracted Pulse Parameters, Raw Time Series | Unsupervised anomaly/novelty detection, can learn compressed representations. | Primarily for anomaly detection, not direct classification of known types without adaptation. | Moderate | 42 |
| Isolation Forest | Extracted Pulse Parameters | Efficient for anomaly detection, works well with high-dimensional data. | Primarily for anomaly detection. | High | 42 |
III. UAV Platform: Dynamics and Agile Reorientation Control
The UAV platform serves as the mobile base for the entire countermeasure system. Its ability to perform rapid and precise attitude maneuvers, particularly a 180-degree yaw reorientation, is a cornerstone of the DTDR operational concept. This section details the specific requirements for such agility, the underlying flight dynamics, and the control strategies necessary to achieve the desired performance.
A. Requirements for Rapid, High-Angle Attitude Maneuvers (e.g., 180° Yaw)
Upon confirmed detection of an HEL threat and determination of its AoA, the UAV must execute a swift 180-degree change in its yaw angle to bring its side-mounted reflective surfaces to bear against the incoming laser. This maneuver is fundamentally different from standard trajectory-following tasks often addressed in UAV control research.51 Instead of tracking a predefined four-dimensional path (position and time), the requirement here is a point-to-point, large-angle reorientation in attitude space, prioritizing speed and final pointing accuracy. The UAV's center of gravity should ideally remain as stable as possible during this turn, or execute a minimal, controlled translation.
Key requirements for this maneuver include:
-
Speed: The reorientation must be completed within the tight timeline allocated by the overall system reaction budget (ideally within 1-2 seconds).
-
Precision: The final yaw angle must accurately align with the threat's AoA, with minimal overshoot or oscillation, to facilitate effective laser reflection by the deployed mirrors.
-
Stability: The UAV must maintain overall flight stability (altitude, roll, and pitch) during and immediately after this aggressive maneuver.
-
Robustness: The maneuver should be executable reliably under various flight conditions and potential external disturbances.
The success of such a rapid reorientation is intrinsically linked to the UAV's maximum angular acceleration and angular rate capabilities, especially in the yaw axis. These performance characteristics are often constrained by factors such as motor and propeller thrust limits, the drone's moments of inertia, and the sophistication of the flight control system design.
B. Quadrotor Flight Dynamics: Maximizing Angular Acceleration and Rates
Quadrotor UAVs are typically chosen for applications requiring agility and hover capabilities. Their attitude is controlled by differential thrust adjustments among their four (or more) rotors, generating torques around the pitch, roll, and yaw axes.55 Achieving the high angular accelerations and rates necessary for the DTDR maneuver demands careful consideration of several factors:
-
Thrust-to-Weight Ratio (TWR): A higher TWR provides greater control authority, as more thrust can be dynamically allocated to generating control torques rather than solely supporting the UAV's weight. A common design heuristic aims for hover at approximately 50% throttle, ensuring significant thrust headroom for maneuvers.58 Comparative data indicates that smaller racing drones (e.g., 3-inch) may have lower TWRs than larger ones (e.g., 5-inch), impacting their relative agility.55
-
Moments of Inertia: Lower moments of inertia around the yaw, pitch, and roll axes allow for higher angular accelerations for a given applied torque. This favors compact and lightweight airframe designs.
-
Motor and Propeller Responsiveness: The dynamic response of the motors and propellers is critical. Fast-responding motors (characterized by a small time constant, τ, as noted in 55) and appropriately designed propellers are essential for rapid torque generation.
-
Actuator Saturation: During aggressive maneuvers, the commanded motor thrusts can reach their maximum or minimum limits. Such actuator saturation can degrade control performance and potentially lead to instability if not properly managed by the flight controller.59
While specific, experimentally validated maximum unconstrained angular accelerations (e.g., in rad/s2) and peak angular rates (e.g., in deg/s) for large-angle, non-trajectory-following reorientations are not extensively detailed in the provided research snippets 61, some inferences can be drawn. Studies on aggressive trajectory tracking for quadcopters have demonstrated linear accelerations up to 2.1g and speeds up to 12.9 m/s, with controllers designed to track yaw rate and yaw acceleration.54 The execution of complex paths like roulette curves inherently requires high angular rates and accelerations.61 Furthermore, parameters from racing drone models 55, such as thrust coefficients (kω) and motor speed capabilities, can be used to estimate maximum achievable control torques and, consequently, angular accelerations, provided the drone's inertial properties are known.
The implication is that standard commercial drones, often optimized for stable and smooth flight, may lack the requisite agility. Specialized platforms, such as racing drones 55 or custom-built high-performance quadcopters developed for research in aggressive maneuvers 54, are more likely candidates for this countermeasure system. A particularly promising, albeit hardware-intensive, avenue for enhancing maneuverability is the use of bidirectional thrust, where propellers can rapidly reverse their direction of rotation or utilize variable-pitch mechanisms on all rotors. This capability, noted to drastically increase control authority 59, would allow for significantly more forceful and direct application of control torques, potentially leading to much faster reorientation maneuvers than achievable with conventional quadcopter motor control logic. The absence of readily available, explicit experimental data on maximum unconstrained angular dynamics for large-angle yaw snaps highlights a critical area for platform-specific characterization or conservative estimation during the design process.
| Parameter | Target Value (Example) | Rationale | Factors Limiting Performance | Relevant Sources |
|---|---|---|---|---|
| Max Sustained Yaw Rate | > 720 deg/s (2 rps) | Enables rapid large-angle change. | Motor/propeller max RPM, aerodynamic drag, control stability | 55 |
| Max Yaw Acceleration | > 20 rad/s2 (~1146 deg/s2) | Achieve high yaw rates quickly. | Max motor torque, drone inertia, TWR | 55 |
| Time for 180° Yaw Maneuver | < 1.0 s | Critical for overall system reaction time. | Max yaw rate and acceleration, control algorithm optimality | |
| Max Pitch/Roll Disturbance during Yaw | < 5 deg | Maintain stability for subsequent mirror aiming. | Control decoupling, aerodynamic symmetry, controller robustness | 54 |
| Pointing Accuracy Post-Maneuver (Body) | < 0.5 deg (pre-FSM) | Provide a stable enough platform for FSM to take over fine pointing. | Controller settling time, sensor noise, structural vibrations |
C. Time-Optimal Attitude Control Algorithms for Rapid Reorientation
To meet the stringent speed requirements for the 180-degree yaw maneuver, the flight control system must employ algorithms that aim to minimize the reorientation time while respecting the UAV's physical limitations.
-
Optimal Control and Bang-Bang Strategies: Theoretical frameworks for time-optimal control of rigid body attitude dynamics often lead to "bang-bang" solutions, where control actuators (in this case, motor torques) are commanded to switch between their maximum and minimum available outputs to achieve the target state in the shortest possible time.62 While 62 demonstrates such an approach for a generic rigid body undergoing large-angle maneuvers, direct implementation on a quadcopter is complicated by underactuation, complex aerodynamics, and real-world actuator dynamics. Nevertheless, these principles guide the development of aggressive control laws.
-
Differential Flatness: This mathematical property of quadrotor dynamics, utilized in some trajectory generation and tracking algorithms 51, allows for the direct computation of feedforward control inputs (including desired angular accelerations and snap – the derivative of jerk) required to achieve specific attitude states. This can form a core component of an aggressive reorientation controller.
-
Incremental Nonlinear Dynamic Inversion (INDI): INDI-based controllers have demonstrated robustness in tracking aggressive trajectories by compensating for external disturbances (like aerodynamic forces) and model uncertainties without requiring explicit prior modeling of these effects.54 This adaptability is highly valuable for maintaining precise control during rapid, potentially unmodeled maneuvers like the DTDR turn.
-
Sliding Mode Control (SMC): SMC is known for its robustness to disturbances and parameter uncertainties. Advanced forms, such as fixed-time SMC, can guarantee convergence to the desired attitude within a predefined time, irrespective of initial conditions.60 This is particularly advantageous for a reactive system like the DTDR. 60 proposes an improved fixed-time SMC for quadcopter attitude control, specifically addressing challenges like energy consumption and actuator saturation during rapid maneuvers.
-
Model Predictive Control (MPC): MPC optimizes control inputs over a predictive horizon by solving an optimization problem at each time step, explicitly considering system dynamics and constraints.51 While powerful, the computational burden of MPC might be a concern for achieving the extremely low latencies required for millisecond-scale reactions, unless highly optimized formulations are used.
-
Deep Reinforcement Learning (DRL): DRL techniques have shown potential for learning complex control policies, including attitude control for UAVs.68 A DRL agent could potentially discover highly agile reorientation maneuvers through interaction with a simulated environment. However, challenges related to training data requirements, sim-to-real transfer, and safety verification for such learned policies in critical applications remain.
In practice, achieving true time-optimal control is difficult due to real-world complexities such as actuator delays, rate limits, sensor noise, and state estimation errors. Therefore, a more pragmatic approach often involves robust, near-optimal control solutions. A hybrid strategy combining feedforward commands (derived from differential flatness or a simplified optimal trajectory) with a robust feedback controller (such as INDI or fixed-time SMC) is likely to yield the best performance. The feedback component would compensate for unmodeled dynamics, disturbances, and errors in the feedforward plan.
A critical consideration for any aggressive maneuver controller is the handling of actuator saturation. The high torques required for rapid reorientation will inevitably push the motors to their operational limits.59 The control algorithm must incorporate anti-windup mechanisms and strategies to maintain stability and control authority even when the desired torques cannot be fully realized. This might involve prioritizing control around the primary maneuver axis (yaw) while temporarily relaxing constraints on other axes (e.g., altitude hold), if mission safety permits.
D. Aerodynamic Effects During Maneuvers and Mirror Deployment
The execution of rapid attitude maneuvers and the sudden deployment of side-mounted mirrors will introduce significant transient aerodynamic forces and moments that the flight control system must counteract to maintain stability and achieve the desired orientation for laser reflection.
-
Maneuver-Induced Aerodynamics: High angular rates and accelerations, particularly in yaw, can lead to complex unsteady aerodynamic phenomena. These include asymmetric airflow over the rotors, changes in induced drag, and potential interactions between rotor downwash and the airframe. These effects can alter control effectiveness and induce unexpected disturbances if not accounted for.69
-
Mirror Deployment Aerodynamics: The rapid deployment of the side-mounted mirrors, which will present as flat plates to the airflow, will generate substantial aerodynamic forces. These forces will primarily manifest as:
-
Drag: An increase in overall drag on the UAV.
-
Asymmetric Forces and Moments: If the mirrors deploy while the UAV is in motion (either translational or rotational), or if one mirror deploys slightly before the other, significant asymmetric drag forces will arise. This can induce yawing, rolling, or pitching moments that perturb the UAV's attitude. For instance, if the UAV is yawing rapidly and the mirrors deploy, the mirror on the side moving forward into the relative wind will experience greater drag, potentially creating a counter-yawing moment or inducing roll. Studies on the aerodynamic impact of external stores or changes in UAV geometry (e.g., underslung containers 69) indicate that even static changes can increase drag by 12-15% and alter lift characteristics. The sudden, dynamic introduction of surfaces like mirrors will have more pronounced transient effects. The phenomenon of ground effect, where proximity to a surface alters airflow and stability 79, provides an analogy; deploying a side mirror is akin to instantaneously introducing a "wall" into the local airflow around the UAV.
-
The magnitude of these aerodynamic disturbances will be highly dependent on the UAV's airspeed at the moment of mirror deployment. At hover, the effects might be relatively minor, dominated by the interaction of the deployed surfaces with the rotor downwash. However, if the UAV is at high forward speed when the laser attack occurs and the mirrors are deployed, the resulting drag and moments could be substantial, akin to deploying small airbrakes asymmetrically.
Computational Fluid Dynamics (CFD) Analysis: CFD simulations are an indispensable tool for predicting and analyzing these transient aerodynamic effects.69 CFD can model the airflow around the UAV during rapid yaw maneuvers and simulate the forces and moments generated by the deploying mirrors at various airspeeds and angles of attack. This data is crucial for designing a flight control system that is robust to these disturbances.
Control System Response: The flight control system, particularly if employing robust techniques like INDI 54, must be capable of rapidly sensing and counteracting these aerodynamic disturbances to maintain the UAV's desired orientation and stability. The timing of mirror deployment relative to the completion of the yaw maneuver is also a critical consideration. It may be advantageous to complete the primary yaw rotation before deploying the mirrors, or to deploy them in a carefully sequenced manner, to minimize adverse aerodynamic interactions. The control system could also incorporate feedforward compensation based on CFD-derived models of the deployment disturbances.
| Phase of Operation | Potential Aerodynamic Disturbance (Force/Moment, Axis) | Estimated Magnitude (Qualitative/CFD-derived) | Control System Compensation Strategy (e.g., INDI, SMC, Feedforward) | Relevant Sources |
|---|---|---|---|---|
| Rapid Yaw Maneuver (High Angular Rates) | Increased asymmetric rotor drag, unsteady body aerodynamics (Yaw, Roll, Pitch moments) | Moderate to Significant, depending on rate and airspeed | INDI, Robust SMC, Adaptive Control, Feedforward based on model | 54 |
| Mirror Deployment (During/After Yaw, Hover) | Rotor downwash interaction with deployed mirrors (Pitch, Roll moments, Vertical force) | Low to Moderate | INDI, Robust SMC | 79 |
| Mirror Deployment (During/After Yaw, Forward Flight) | High asymmetric drag on deployed mirrors (Significant Yaw, Roll, Pitch moments, Drag force) | Significant to Very Significant, especially at high speeds | INDI, Robust SMC with high control authority, Feedforward compensation | 61 |
| Sustained Flight with Deployed Mirrors | Increased overall drag, altered lift distribution, potential buffeting (All axes) | Moderate, persistent | Adaptive control, modified trim settings, INDI | 69 |
IV. Deployable High-Reflectivity Mirror Subsystem
The deployable mirror subsystem is central to the countermeasure's ability to reflect the incident HEL beam. This subsystem encompasses the optical mirrors themselves, designed for high reflectivity and damage resistance, and the ultra-fast mechanisms required to deploy and stabilize them.
A. Optical Mirror Design for High-Power Laser Reflection
The mirrors must satisfy several demanding criteria: they must be lightweight to minimize impact on UAV agility and payload capacity; exhibit exceptionally high reflectivity at the anticipated threat laser wavelengths to maximize the energy directed back at the source and minimize self-heating; and possess a high Laser-Induced Damage Threshold (LIDT) to withstand the intense laser energy during the engagement without suffering damage or significant optical distortion.
1. Lightweight, Thermally Stable Substrate Materials:
The choice of substrate material is critical for achieving the desired mechanical and thermal properties.
-
Silicon Carbide (SiC): This ceramic material is a leading candidate due to its superior stiffness-to-weight ratio, excellent thermal stability (low coefficient of thermal expansion), and high thermal conductivity. Foam-core SiC mirrors, in particular, offer further weight reduction while maintaining structural rigidity and mitigating "print-through" effects often seen with conventionally lightweighted mirrors. SiC is well-suited for HEL applications due to its ability to rapidly dissipate heat and resist thermal distortion.81
-
Aluminum (Al) and Aluminum Alloys: These metals are frequently used for lightweight scanning mirrors, especially when intricate shapes or integrated mounting features are required. Aluminum can be engineered with ribbed or pocketed back structures to further reduce mass.82 However, aluminum has a relatively high coefficient of thermal expansion, making thermal management critical. To achieve optical quality surfaces and prevent oxidation, aluminum mirrors typically require an intermediate layer of electroless nickel plating, which provides a smooth, amorphous surface for subsequent optical coating.82
-
Fused Silica (UVFS): UV-grade fused silica is a high-purity glass offering excellent optical homogeneity, a low coefficient of thermal expansion, and good performance in UV and high-power laser applications, particularly when superpolished to achieve very low surface roughness (≤1Å RMS).83
-
Zerodur®: This glass-ceramic material is known for its near-zero coefficient of thermal expansion over a wide temperature range, making it ideal for applications subject to significant temperature fluctuations.83 Lightweight mirror concepts have utilized Zerodur face sheets.84
-
Beryllium (Be): Beryllium offers attractive thermal properties (high thermal conductivity, low density) and is inherently lightweight. However, its toxicity and manufacturing challenges, along with a density that can sometimes result in heavier optics than glass counterparts if not optimally designed, are considerations.81
-
Flexible Composites (e.g., Triaxially Woven Fabric-Reinforced Silicone - TWFS): While materials like TWFS have been successfully used for deployable RF reflector antennas due to their ability to be compactly stowed and retain shape upon deployment 85, their suitability for direct HEL reflection is highly questionable. Achieving the optical surface figure (flatness) and smoothness required for coherent laser reflection, along with the necessary LIDT, would be extremely challenging with current flexible composite technologies. They are primarily designed for RF applications where surface precision requirements are orders ofmagnitude less stringent.
The selection of the substrate material involves a careful trade-off analysis considering thermal stability (to prevent warpage under laser load), stiffness (to maintain flatness under dynamic loads), weight (for SWaP and agility), and manufacturability/cost. For HEL applications, SiC currently appears to be a strong contender due to its balanced properties.81
2. High Laser-Induced Damage Threshold (LIDT) Coatings (Dielectric/Metallic):
The mirror surface must be coated to achieve high reflectivity at the threat laser's wavelength(s) and to withstand the laser's intensity.
-
Dielectric Coatings: These consist of multiple thin layers of dielectric materials (e.g., oxides like TiO2, SiO2, Ta2O5, HfO2, Al2O3) with precisely controlled thicknesses. By exploiting interference effects, dielectric mirrors can achieve extremely high reflectivity (R > 99.9%, and in some cases > 99.99%) for specific laser wavelengths and angles of incidence (AoI).87 They generally offer higher LIDT values compared to metallic coatings, especially for pulsed lasers. For instance, LIDTs of 30 J/cm² (at 1064 nm, 10 ns pulse) are achievable.87 However, dielectric coatings are inherently wavelength-specific and their performance (reflectivity and phase shift upon reflection) is sensitive to the AoI.88 Designs can be optimized for specific laser lines (e.g., Nd:YAG harmonics at 1064 nm, 532 nm, 355 nm 87) or for broader bandwidths, though often with some compromise in peak reflectivity or LIDT.
-
Metallic Coatings:
-
Silver (Ag): Offers high reflectivity (>97%) across a broad spectral range (visible to far-infrared, e.g., 450 nm - 15 µm).89 However, silver tarnishes easily and requires a protective dielectric overcoat (e.g., SiO2), which can slightly reduce reflectivity and LIDT. Protected silver coatings might have pulsed LIDTs around 1 J/cm² (1064 nm, 10 ns).91 Ultrafast-enhanced silver coatings can achieve >99% reflectivity for S-polarized light in specific NIR bands.91
-
Gold (Au): Provides excellent reflectivity (>96-97%) in the infrared spectrum (typically 800 nm to 20 µm) and is relatively inert.89 Protected gold coatings can have pulsed LIDTs around 2 J/cm² (1064 nm, 10 ns).91 Unprotected gold may offer higher LIDT for specific long-wavelength pulsed lasers (e.g., 10.6 µm) but is soft and easily damaged.
-
Aluminum (Al): Offers good reflectivity (>85-90%) from UV to IR (200 nm - 15 µm) but oxidizes readily and requires protection.89 Its LIDT is generally lower than that of silver or gold for HEL applications.
-
-
LIDT Considerations:
-
The LIDT of an optical coating is a critical parameter indicating the maximum laser fluence (for pulsed lasers, typically in J/cm²) or intensity (for CW lasers, typically in W/cm²) it can withstand before damage occurs.92
-
For CW lasers, damage is primarily thermal, driven by absorption in the coating and substrate. LIDT is specified in W/cm² and is highly dependent on factors like exposure time, beam diameter, material thermal properties, presence of defects, and cooling conditions (e.g., airflow, heat sinking).92 Studies show that CW LIDT tends to decrease with increased beam diameter and exposure time.93
-
For pulsed lasers, damage can result from a combination of mechanisms, including thermal absorption (especially for longer pulses or high repetition rates) and dielectric breakdown (for short, high peak power pulses).92 Pulsed LIDT (J/cm²) is dependent on pulse duration, wavelength, and repetition rate. Generally, LIDT increases with increasing pulse duration.92
-
Dielectric vs. Metallic LIDT: For specific design wavelengths, dielectric mirrors typically offer significantly higher LIDT values than metallic mirrors, particularly for pulsed laser applications.87 Research continues on enhancing the LIDT of multilayer dielectric coatings, for example, by using mixtures of materials like HfO2 and SiO2 or HfO2 and Al2O3.95
-
-
Angular Dependence of Reflectivity: While metallic coatings maintain relatively consistent reflectivity over a wide range of AoIs, dielectric coatings are more sensitive. Their peak reflectivity is optimized for a specific AoI (or a narrow range). Deviations from this design angle can lead to a significant drop in reflectivity, especially for narrowband designs.88 Broadband dielectric mirror designs aim to provide high reflectivity over a wider range of AoIs (e.g., 0° to 45°) 87, which is important for this application as the drone will be maneuvering and the exact AoI of the laser impact may vary.
Given the high-power nature of the threat, dielectric mirrors are generally preferred if the anticipated laser wavelength(s) can be reasonably defined. Their superior reflectivity and LIDT are advantageous for maximizing the reflected energy and ensuring mirror survivability.4 If the system must counter a wide range of unknown laser wavelengths, enhanced metallic coatings might be considered as a compromise, but this would likely come at the cost of lower reflectivity and reduced LIDT. It is crucial that the DTDR sequence, particularly the detection and mirror deployment phases, is executed faster than the time it takes for the incident laser energy to exceed the mirror's LIDT and cause damage. The mirror is intended to reflect the damaging laser pulse, not to absorb its energy indefinitely.
3. Mirror Geometry and Sizing for Effective Reflection and SWaP Optimization:
The physical dimensions and shape of the mirrors are critical design parameters.
-
Size: The mirrors must be sufficiently large to intercept a substantial portion of the incoming HEL beam. This requires an estimation of the attacking laser's spot size at the drone's engagement distance, considering factors like the source laser's beam divergence and pointing accuracy.
-
Shape: For simple retro-reflection of a beam incident along the drone's new forward axis (after the 180° yaw), flat (plano) mirrors are appropriate.
-
Thickness and Weight: Mirror thickness influences its rigidity and thermal mass. Thicker mirrors are more resistant to thermal distortion and mechanical vibrations but add weight. The overall size and thickness are heavily constrained by the UAV's payload capacity (SWaP) and the requirement for rapid deployment. Smaller, thinner mirrors are lighter and can be actuated more quickly but may be more susceptible to thermal lensing or warping and could have a lower absolute LIDT due to reduced thermal mass.
-
Number and Placement: Typically, two mirrors would be required, one on each side of the UAV, to provide coverage after a 180-degree yaw maneuver regardless of the initial relative bearing of the threat. Their placement must ensure an unobstructed path for the reflected beam and minimize aerodynamic interference when stowed and deployed.
The determination of mirror size represents a trade-off: larger mirrors increase the probability of intercepting an imperfectly aimed incoming laser beam but are heavier, require more powerful and potentially slower deployment mechanisms, and will have a greater aerodynamic impact during and after deployment. An optimal size must be derived from an analysis of anticipated threat beam characteristics, UAV platform limitations, and the performance of the deployment mechanism.
| Material | Density (g/cm³) | Thermal Conductivity (W/mK) | CTE (ppm/K) | Stiffness (E, GPa) | Max Op. Temp (°C) | Manufacturability | Cost (Relative) | Pros | Cons | Relevant Sources |
|---|---|---|---|---|---|---|---|---|---|---|
| Silicon Carbide (SiC) | ~3.1-3.2 | ~120-200 | ~2.2-4.0 | ~400-450 | >1000 | Moderate-Hard | High | Excellent stiffness/weight, thermal stability, good for HEL | More expensive, can be brittle | 81 |
| Aluminum (6061-T6) | ~2.7 | ~167 | ~23.6 | ~69 | <200 (optical) | Easy | Low | Lightweight, easy to machine complex shapes, good thermal conductivity | High CTE, lower stiffness, needs coating for optical surface/protection | 82 |
| Fused Silica (UVFS) | ~2.2 | ~1.38 | ~0.55 | ~73 | ~1000 | Moderate | Moderate | Low CTE, excellent optical homogeneity, good for UV/high power | More brittle than metals, lower thermal conductivity than SiC/Al | 83 |
| Zerodur® | ~2.53 | ~1.46 | ~±0.02 | ~91 | ~600 | Moderate | High | Near-zero CTE, excellent dimensional stability | More expensive, lower thermal conductivity than SiC/Al | 83 |
| Beryllium (Be) | ~1.85 | ~216 | ~11.5 | ~303 | ~700 | Hard (Toxic) | Very High | Very lightweight, high thermal conductivity, stiff | Toxic, expensive, challenging to machine, higher CTE than SiC/FS | 81 |
| Coating Type | Wavelength Range (nm) | Avg. Reflectivity (Design AoI, e.g., 45°) | Pulsed LIDT (J/cm² @ typical pulse) | CW LIDT (kW/cm² @ typical conditions) | Durability (Scratch/Dig, Environmental) | AoI Sensitivity | Key Sources |
|---|---|---|---|---|---|---|---|
| Dielectric Multilayer (e.g., for 1064nm) | Narrowband (e.g., 1064±50) | >99.9% | 10-30 J/cm² (10ns, 1064nm) 87 | 1-10 MW/cm² (CW, depends on design) 90 | Good (e.g., 10-5 S/D), MIL-Spec 89 | Moderate-High | 87 |
| Dielectric Multilayer (e.g., for 532nm) | Narrowband (e.g., 532±25) | >99.9% | 5-15 J/cm² (10ns, 532nm) 87 | Lower than 1064nm, design dependent | Good (e.g., 20-10 S/D), MIL-Spec | Moderate-High | 87 |
| Broadband Dielectric | e.g., 400-750, 750-1100 | >99% 91 | 0.2-1 J/cm² (wavelength/pulse dependent) 91 | 0.5-1 kW/cm (wavelength dependent) 91 | Good (e.g., 20-10 S/D) | Low-Moderate | 87 |
| Protected Silver (e.g., -P01) | 450 - 20000 | >97% (VIS-NIR), >95% (IR) 89 | ~1 J/cm² (10ns, 1064nm); 0.225 J/cm² (99fs, 800nm) 91 | 0.5 kW/cm (1070nm) 91 | Good (40/20 S/D), MIL-M-13508C 89 | Low | 89 |
| Protected/Enhanced Gold (e.g., -M01) | 800 - 20000 | >96% (NIR), >98% (MIR) 89 | ~2 J/cm² (10ns, 1064nm); 3 J/cm² (100ns, 10.6µm for MIR Enhanced) 91 | 0.5 kW/cm (1070nm) 91 | Good (40/20 S/D), MIL-M-13508C 89 | Low | 89 |
| UV-Enhanced Aluminum (e.g., -F01) | 250 - 450 | >90% 91 | 0.25-0.3 J/cm² (10ns, UV) 91 | 0.3 kW/cm (1064nm, indicative) 91 | Fair-Good | Low | 91 |
B. Ultra-Fast Mirror Deployment and Locking Mechanisms
The mirrors must transition from a stowed, protected position to a precisely defined operational angle in an exceptionally short timeframe, targeting less than 50 milliseconds, and ideally under 20 milliseconds. Once deployed, they must be rigidly locked to withstand flight loads and maintain optical alignment.
1. Actuator Selection for Sub-50ms Deployment:
Achieving such rapid deployment necessitates careful actuator selection.
-
Pre-loaded Springs with Fast Release Triggers: Spring-actuated mechanisms offer the potential for very rapid deployment by releasing stored elastic energy. U.S. Patent 10,112,698 B2 details a spring-loaded system for UAV wing deployment designed for quick motion after a high-G launch.97 The critical element for speed then becomes the trigger mechanism. A non-explosive pyrotechnic (NEP) device or a fast-acting Shape Memory Alloy (SMA) wire could serve as this trigger. 101 describes a non-explosive release actuator using an SMA wire achieving a 50 ms release time for a substantial 15 kN preload, suggesting SMAs are viable for triggering pre-loaded systems. This hybrid approach—springs for motive force, fast trigger for release—combines stored energy for speed with precise electrical initiation.
-
Voice Coil Actuators (VCAs): VCAs are known for their high speed, precise controllability, and direct-drive nature, making them suitable for applications requiring rapid, short-stroke movements. They are commonly used in Fast Steering Mirrors 98 and could potentially drive small, lightweight mirror deployment mechanisms directly if the force and stroke requirements are within their capabilities.
-
Piezoelectric Actuators: These offer extremely fast response times (sub-millisecond to millisecond range 99) but typically provide very small displacements. For larger movements, they often require mechanical motion amplification (lever arms, flexure-based amplifiers 99) or are used in resonant systems. While perhaps not suitable for the primary deployment stroke of a sizable mirror, they could be integral to ultra-fast latching mechanisms or fine position adjustments post-deployment.
-
Other Micro Actuators: The general category of micro actuators encompasses various technologies (thermal, magnetic, electrostatic) with response times often in the millisecond range, suitable for controlling small optical elements or latches in compact systems.100
The overall system reaction time budget is stringent. If the LWR response is less than 50 ms 15, and mirror deployment also consumes around 50 ms (as in the SMA release example 101), a significant portion of the sub-200 ms total reaction goal is already used before the UAV even completes its turn. Therefore, pushing mirror deployment times towards the 10-20 ms range is highly desirable, favoring very fast voice coils or highly optimized spring-release mechanisms with minimal trigger latency.
2. Kinematic Design for Side-Mounted Pop-Out Mirrors:
The mirrors are envisioned to be stowed flush or near-flush with the UAV's fuselage to minimize aerodynamic drag during normal flight, deploying outwards to a precise operational angle (e.g., 45 degrees relative to the drone's longitudinal axis to achieve retro-reflection after a 180-degree yaw).
-
Hinge Mechanisms: Simple, robust hinge designs are preferred for reliability.97 The design must ensure precise angular positioning at the end of travel and high rigidity when locked.
-
Compact Stowage: The stowed configuration must protect the delicate mirror surface from environmental factors and operational hazards.85 The deployment mechanism, including its stowed components and deployed mirrors, must be structurally robust to withstand the UAV's operational environment, including vibrations and G-forces experienced during aggressive maneuvers, without risking accidental deployment, failure to deploy, or inability to lock securely under stress.
3. Precision Latching for Post-Deployment Stability:
Once the mirror reaches its operational angle, it must be locked rigidly and instantaneously to ensure the stability required for accurate laser reflection. Any play, wobble, or vibration in the deployed mirror will degrade pointing accuracy.
-
Mechanical Latches: Positive locking mechanisms such as spring-loaded detents, over-center toggle latches, or solenoid-actuated locking pins are candidates. Such mechanisms provide a definitive locked state. 117 mentions latch-based mechanisms for securing propulsion system components, indicating their utility in UAV systems for robust locking.
-
Bistable Mechanisms: These are designed to have two stable states (stowed and deployed) and can provide inherent locking once transitioned from one state to the other, often with a snap-action. The locking mechanism must engage rapidly and positively at the end of the deployment stroke, with minimal bounce or settling time. The rigidity of the lock is paramount for maintaining the precise optical alignment needed for retro-reflection. Relying solely on actuator holding force is unlikely to provide sufficient stability against vibrations and dynamic loads.
| Actuator Type | Achievable Deployment Time (ms) (Est.) | Force/Torque Output (Relative) | Precision/Controllability | SWaP Profile | Maturity/Reliability | Pros for Mirror Deployment | Cons for Mirror Deployment | Relevant Sources |
|---|---|---|---|---|---|---|---|---|
| Pre-loaded Spring + Fast Trigger (NEP/SMA) | 10 - 50 | High (Spring Dependent) | Low (Ballistic deployment) | Low-Moderate | Trigger: High (NEP), Mod (SMA) | Very fast release, high force, simple mechanics post-trigger. | One-shot (NEP) or slow reset (SMA trigger), less control over deployment profile. | 97 |
| Fast Voice Coil Actuator (VCA) | 5 - 30 | Moderate | High | Moderate | High | Fast, precise, controllable motion profile, good for direct drive. | Stroke/force limitations for larger mirrors, continuous power may be needed to hold. | 98 |
| Fast Shape Memory Alloy (SMA) - Direct Drive | > 50 (current tech for significant force) | Moderate-High | Moderate | Low | Moderate (fatigue, speed limits) | Compact, high force/weight ratio. | Generally slower than other options for direct, large, fast movement; thermal dependence. | 100 |
| Piezoelectric Actuator (with amplification) | < 1 - 10 | Low (High with amplification) | Very High | Low-Moderate | High | Extremely fast, very precise. | Small native displacement requires significant amplification for mirror deployment. | 99 |
| Non-Explosive Pyrotechnic (NEP) - Direct | < 5 - 20 | Very High | Low (Ballistic) | Low | High (for one-shot release) | Extremely fast, very high force. | One-shot deployment, generates some shock (though "non-explosive"). | 101 |
C. Active Pointing and Stabilization of Deployed Mirrors
Even with a highly agile UAV, precise flight control, and rapid, well-locked mirror deployment, residual errors from platform vibrations, slight misalignments in deployment, and atmospheric disturbances can compromise the accuracy of the reflected laser beam. Active compensation using Fast Steering Mirrors (FSMs) is likely essential to achieve the sub-milliradian pointing accuracy required to hit a distant laser source.
1. Integration of Miniature Fast Steering Mirrors (FSMs):
FSMs are compact optical devices capable of providing high-bandwidth, two-axis (tip/tilt) angular adjustment of a mirror surface with high precision.81
-
Function: In this system, an FSM would be used to make fine, rapid corrections to the pointing of the reflected laser beam, compensating for errors that the main drone maneuver and mirror deployment cannot address.
-
Integration: An FSM could be a small, secondary mirror in the optical path after the main deployed mirror, or, if SWaP and complexity allow, the main deployable mirror itself could be designed as an FSM. The former is more likely for this application, where the main mirror handles the bulk reflection and the FSM provides fine angular adjustments.
-
Actuation and Control: FSMs typically use voice coil actuators 98 or piezoelectric actuators 99 to achieve fast and precise tilts. They operate in a closed-loop control system, utilizing internal position sensors (e.g., optical encoders, strain gauges 99) to provide feedback on the mirror's orientation.
-
Performance: Miniature FSMs can offer angular ranges from microradians to milliradians (or even degrees for larger units 98), with resonant frequencies extending from hundreds of Hertz to over 1500 Hz.104 This high bandwidth allows them to compensate for rapid disturbances.
The inclusion of FSMs is critical because relying solely on the UAV's body pointing accuracy (which might have errors of degrees 54) and the passive precision of the deployed main mirrors is highly unlikely to achieve the µrad-level pointing needed to effectively hit a small laser source aperture at tactically relevant distances. FSMs bridge this gap by providing a fine-pointing overlay to the coarse pointing achieved by the drone and main mirrors.
2. Vibration Isolation and Compensation Strategies:
UAVs are inherently vibrating platforms due to motors, propellers, and aerodynamic forces. These vibrations can significantly degrade the pointing stability of the reflected laser beam.
-
Passive Isolation: Mounting the entire mirror assembly (main deployed mirror and FSM) on viscoelastic damping materials or specialized vibration isolation mounts can help attenuate some of the platform-induced jitter.
-
Active Compensation via FSM: The primary role of the FSM in this context is active vibration compensation. By sensing either the platform jitter (e.g., through high-speed IMU data fed forward to the FSM controller) or the error in the reflected beam's pointing (e.g., using a dedicated quad-cell detector that tracks a beacon from the laser source or a fraction of the reflected beam), the FSM can make real-time adjustments to counteract the vibrations and stabilize the outgoing beam.105105 explicitly mentions FSMs for high-frequency vibration cancellation in UAV photography.
The FSM control loop requires its own high-speed sensor input to perform these corrections effectively. This could be a dedicated optical tracking sensor that provides an error signal relative to the laser source, or a sensor fusion approach combining refined AoA data from the LWR with high-rate inertial data from the UAV's IMU. This allows the FSM to distinguish between desired pointing changes and undesired jitter, ensuring the reflected beam remains locked onto the threat source.
V. Laser Beam Retro-Reflection and Aiming Precision
The ultimate goal of the DTDR system is to accurately reflect the incident HEL beam back to its source. This requires not only precise orientation of the drone and its mirrors but also a thorough understanding and mitigation of all factors that can degrade pointing accuracy.
A. Principles of Accurate Laser Reflection to Source
For perfect retro-reflection using a flat mirror, the law of reflection dictates that the angle of incidence equals the angle of reflection. To direct the beam back along its incoming path, the mirror surface must be oriented normal to the bisector of the angle formed by the incoming laser beam and the desired outgoing path (i.e., back to the source). In the DTDR concept, after the UAV executes a 180-degree yaw maneuver, the incoming laser is approximately aligned with the drone's new forward direction (or directly from one side if the turn is to present a side mirror). If side-mounted mirrors are deployed at, for example, a 45-degree angle relative to the drone's longitudinal axis, an incoming beam from the front would be reflected 90 degrees (in the drone's reference frame), effectively sending it back towards the source.
The primary challenge lies in achieving and dynamically maintaining this precise mirror orientation relative to the actual direction of the laser source, in the presence of UAV motion, vibrations, atmospheric disturbances, and potential movement of the laser source itself. This transforms the problem from a static alignment task into a dynamic, closed-loop pointing and tracking challenge. The system must continuously estimate the source direction based on the incoming laser (via the LWR's AoA measurement), orient its reflective surfaces accordingly, and then employ fine-tuning mechanisms (like FSMs) to make micro-corrections. This continuous control is essential to ensure the reflected beam accurately impinges upon the sensitive optics of the attacking LWS.
B. Comprehensive Pointing Error Budget Analysis
A meticulous pointing error budget analysis is crucial for assessing the feasibility of the retro-reflection concept and for guiding the design tolerances of each subsystem. The objective is to ensure that the total angular error of the reflected beam is significantly smaller than the beam's divergence and also smaller than the apparent angular size of the laser source's aperture as viewed from the drone. An analogous framework for pointing error budgets in free-space optical communication systems 23 provides a valuable reference.
The key sources contributing to the overall pointing error include:
-
UAV Platform Jitter and Attitude Control Inaccuracies: Residual vibrations from motors and aerodynamics, coupled with inherent inaccuracies in the UAV's flight control system to achieve and maintain the precise target yaw angle, contribute significantly to pointing errors.23 Even advanced flight controllers for aggressive maneuvers report RMS yaw tracking errors in the range of 1.9 to 5.1 degrees 54, which is far too large for direct, uncompensated reflection and underscores the absolute necessity for FSM-based fine pointing.
-
LWR Angle of Arrival (AoA) Measurement Error: The accuracy with which the LWR determines the true direction of the incoming laser directly impacts the initial aiming of the reflected beam. Reported AoA accuracies vary: segmented detector systems like the D5 offer coarse AoA 15; the Excelitas EXACTD-362 module specifies ±0.8° 9; and advanced techniques like cylindrical lens systems claim resolutions around 0.105°.18 This initial AoA error sets the baseline for the FSM's correction task.
-
Mirror Deployment and Locking Tolerances: Mechanical imprecision in the final deployed angle of the main mirrors and any instability or play in their locking mechanisms will introduce static and dynamic pointing errors.
-
FSM Control Loop Performance: The FSM itself will have residual jitter and tracking errors, dependent on its control bandwidth, sensor noise, and actuator resolution. High-performance FSMs in satellite laser communication systems aim to reduce line-of-sight (LOS) jitter to less than 1 µrad.23
-
Atmospheric Propagation Effects (Turbulence, Scintillation, Beam Wander): The Earth's atmosphere is not a benign medium. Temperature and pressure fluctuations create refractive index variations, leading to atmospheric turbulence. This turbulence causes several deleterious effects on laser beam propagation:
-
Beam Wander: Random deflection of the beam from its intended path.
-
Beam Broadening: Increase in the beam's spot size beyond diffraction limits.
-
Scintillation: Rapid fluctuations in laser intensity at the receiver. These effects will degrade the quality and pointing accuracy of both the incoming threat laser (affecting AoA measurement) and the outgoing reflected countermeasure beam.20 The reflected beam must traverse this distorting medium to reach the source.
-
-
Thermal Distortion of Mirrors: Absorption of even a small fraction of the incident HEL energy can cause the mirrors to heat up. If this heating is non-uniform or if the substrate material has a significant coefficient of thermal expansion, the mirror surface can distort, altering the reflected wavefront and degrading beam quality and pointing.81
-
Beam Divergence of the Reflected Beam: The reflected laser beam will naturally diverge due to diffraction from the finite aperture of the drone's mirror. For a given wavelength, a smaller mirror will result in greater beam divergence.106 This divergence must be minimized to ensure that sufficient energy density from the reflected beam reaches the laser source. Adaptive beam divergence control has been studied to mitigate scintillation effects due to pointing errors in FSO links 22, a concept potentially relevant here.
A quantitative error budget will likely reveal that the raw pointing capability of the UAV combined with the AoA accuracy of the LWR is insufficient for direct, unaided retro-reflection over tactically relevant distances. For example, even a cumulative error of 0.5 degrees (approximately 8.7 milliradians) from these sources would result in a miss distance of 8.7 meters at a 1-kilometer range, far too large to hit the typically small aperture of an LWS. This reinforces the conclusion that FSMs are indispensable for fine-pointing compensation. Furthermore, the two-way passage of the laser beams (incoming threat, outgoing reflection) through the atmosphere means that atmospheric distortions are a compounded problem, affecting both the ability to sense the threat's origin and the ability to effectively return energy to that origin. While advanced adaptive optics (e.g., deformable mirrors) are used in high-power laser systems to compensate for atmospheric distortion, their complexity and SWaP typically make them unsuitable for small UAV applications. The system must therefore be designed with sufficient performance margin to accommodate some level of atmospheric degradation.
| Error Source | Error Value (1-sigma, example) | Contribution to Reflected Beam Error (Calculation Factor) | Notes/Mitigation |
|---|---|---|---|
| UAV Jitter (Pitch/Yaw) | 500 µrad (platform stability) | x2 (reflection) | FSM compensation, passive damping. |
| UAV Attitude Control Error (Yaw) | 1 mrad (post-maneuver hold) | x2 | High-performance flight controller, FSM correction. |
| LWR AoA Accuracy | 2 mrad | x1 (initial aiming error for FSM) | High-resolution LWR, sensor fusion. |
| Main Mirror Deployment Angle Error | 200 µrad | x2 | Precision mechanism, robust locking. |
| Main Mirror Lock Stability (Vibration) | 100 µrad | x2 | Rigid locking mechanism, FSM compensation. |
| FSM Residual Jitter/Control Error | 10 µrad | x1 (direct error of fine pointing) | High-bandwidth FSM, low-noise feedback sensors. |
| Thermal Mirror Distortion (Dynamic) | 5 µrad (substrate dependent) | x2 | High thermal conductivity substrate (e.g., SiC), highly reflective coating to minimize absorption. |
| Atmospheric Tilt/Wander (Uncompensated) | 20-50 µrad (path dependent) | x1 (affects outgoing beam directly) | Difficult to compensate fully on UAV; ensure sufficient reflected beam power margin and low divergence. |
| RSS Total (Illustrative) | ~2.9 mrad (without FSM) | This would be dominated by UAV attitude and LWR AoA. | |
| RSS Total with FSM (Illustrative) | ~50-100 µrad (FSM limited) | Assumes FSM effectively compensates larger errors down to its own residual jitter and atmospheric limits. |
(Note: Actual values are highly dependent on specific component choices and operating conditions. This table is for illustrative purposes to show contributing factors. The "Contribution Factor" indicates how a mirror tilt error translates to beam deviation; for reflection, a mirror tilt of θ causes a beam deviation of 2θ relative to the mirror normal. If the error is in knowing the incoming beam direction, it's a 1:1 error for the reflected beam's initial aim.)
C. Control Strategy for Reflected Beam Aiming
The control strategy for aiming the reflected beam is a multi-stage process involving the coordinated action of the LWR, the UAV's flight control system, and the FSM.
-
Initial Coarse Aiming: Upon confirmed threat detection, the UAV executes the rapid yaw maneuver to align its body (and thus the stowed mirror mechanisms) approximately towards the AoA provided by the LWR. Simultaneously or immediately after, the main reflective mirrors are deployed to their predetermined angle (e.g., 45° relative to the drone's body). This establishes a coarse alignment of the reflected beam path.
-
FSM Fine-Pointing and Stabilization: Once the main mirrors are deployed and the UAV has generally stabilized its attitude, the FSM takes over the fine-pointing task. The FSM requires a precise error signal to null out residual pointing errors. This error signal can be derived from:
-
Refined LWR AoA Data: The LWR might provide updated, higher-precision AoA measurements once the initial gross motion has ceased, or if it incorporates a tracking mode.
-
Dedicated Tracking Sensor: A small, co-aligned optical sensor (e.g., a quadrant photodiode or a miniature camera) could attempt to detect a feature of the laser source (e.g., its aperture glint, or a dedicated beacon if available, though unlikely for hostile sources) and provide an error signal to the FSM controller.
-
Feedforward from UAV IMU: High-rate data from the UAV's Inertial Measurement Unit (IMU) can be used to predict and compensate for platform jitter and small attitude deviations, allowing the FSM to maintain its orientation in inertial space. The FSM control algorithm itself will typically be a high-bandwidth Proportional-Integral-Derivative (PID) controller, possibly augmented with adaptive feedforward elements to enhance tracking performance against dynamic disturbances like UAV vibrations or target motion.104
-
A significant challenge in this control loop is the "hit confirmation" for the reflected beam: how does the drone verify that its countermeasure laser beam is accurately impinging on the hostile LWS optics? Without direct feedback from the target, the system operates in an open-loop pointing mode based on the LWR's AoA data. Indirect feedback might be gleaned by observing changes in the incoming threat laser's characteristics (e.g., cessation of lasing, erratic behavior) if the counter-reflection is successful in damaging or disrupting the source. Some advanced LWS rely on sensing their own reflected light for focusing and tracking 4; disrupting this could be an objective. The HELIOS system, for example, uses a counter-laser to confuse the attacking laser's beam control 4, suggesting a similar principle of interfering with the attacker's sensing loop.
The control system for the FSM must be tightly coupled with both the LWR and the UAV's IMU.98 The FSM needs the drone's instantaneous attitude to stabilize the reflected beam in an inertial frame, and it needs the most accurate available AoA of the threat to direct that beam. This constitutes a sensor fusion and real-time control problem that is critical to the success of the reflection. Patent US20220321198A1 109, while focused on Reconfigurable Intelligent Surfaces (RIS) for RF communication, describes the concept of actively configuring a passive reflective surface on a UAV to compensate for UAV oscillations and steer a beam, which is conceptually analogous to the FSM's role here.
VI. Integrated System Control and Data Architecture
The successful execution of the DTDR sequence, with its demanding requirements for speed, precision, and synchronization, hinges on a robust and high-performance integrated system control and data architecture. This architecture must seamlessly link perception (LWR, hit confirmation sensors), decision-making (AI-based threat assessment, maneuver planning), and actuation (flight control, mirror deployment, FSM pointing).
A. Onboard Processing: Hardware and Software Requirements
The computational demands of real-time sensor fusion, AI inference, agile flight control, and precision actuation necessitate significant onboard processing capabilities.
1. High-Performance Embedded Computing:
A combination of processing elements is likely required to meet the diverse computational needs:
-
System-on-Chip (SoC) Platforms: Modern SoCs (e.g., NVIDIA Jetson series, Qualcomm Snapdragon Flight platforms) integrate multi-core CPUs, powerful GPUs suitable for parallel processing and AI acceleration, and sometimes dedicated AI co-processors or FPGAs. These offer a balance of general-purpose processing and specialized acceleration in a SWaP-constrained package. Reports indicate the use of compact chips with embedded software for AI-driven functions on advanced UAVs.47
-
Field-Programmable Gate Arrays (FPGAs): FPGAs excel at implementing massively parallel, low-latency processing pipelines. They are ideal for hardware acceleration of specific, time-critical tasks such as:
-
High-speed digital signal processing directly from LWR photodetector ADCs (e.g., pulse parameter extraction, PIM code analysis).
-
Implementing very fast control loops for FSMs.
-
Custom logic for sensor fusion and synchronization.
-
-
Microcontrollers (MCUs): MCUs (e.g., ARM Cortex-M series) are suitable for lower-level tasks such as interfacing with individual sensors, controlling mirror deployment actuators, managing power distribution, and handling basic housekeeping functions.
A distributed processing architecture may be optimal. A central, high-level processor (likely an SoC) could handle complex tasks like AI-based threat assessment, overall mission management, and high-level flight path planning. Dedicated MCUs or FPGAs would then manage the time-critical, low-level sensor interfaces and actuator control loops (e.g., an FPGA for LWR front-end processing, a DSP or MCU for the FSM control loop). This hierarchical approach helps to distribute the computational load and ensure deterministic real-time performance for the most critical functions.110 A significant design constraint is the power consumption of these high-performance processing units, which can be substantial and directly impact UAV flight endurance.48 Therefore, careful selection of power-efficient hardware and optimization of algorithms are crucial.
2. Real-Time Operating Systems (RTOS):
To ensure deterministic behavior and meet the stringent low-latency requirements of the DTDR sequence, a Real-Time Operating System (RTOS) is essential for managing tasks on the primary processors.111
-
Benefits: An RTOS provides preemptive multitasking, priority-based scheduling, fast interrupt handling, and inter-task communication mechanisms, all of which are critical for guaranteeing that time-sensitive operations (like processing LWR data, calculating flight control commands, and actuating mirrors) are executed within their deadlines. RTOS usage can improve Worst-Case Execution Time (WCET) and reduce overall system latency.112
-
Candidates: Popular RTOS choices for embedded systems include FreeRTOS, Zephyr RTOS, VxWorks, and QNX. The selection depends on factors like hardware support, feature set, safety certification requirements (if any), and developer familiarity.
-
Application Design: Effective RTOS application design involves careful decomposition of the system into concurrent tasks, appropriate assignment of task priorities, management of shared resources, and robust inter-task communication and synchronization.112
The overall software architecture should be modular, with well-defined interfaces between the various subsystems (LWR data processing, AI threat assessment, flight control, mirror deployment control, FSM pointing, etc.). This facilitates development, testing, integration, and future upgrades.
B. Low-Latency Data Bus and Communication Architecture
Reliable, high-bandwidth, and low-latency communication between sensors, processors, and actuators is paramount for the synchronized operation of the DTDR system.
-
Candidate Technologies:
-
Time-Sensitive Networking (TSN): TSN is a suite of IEEE 802 Ethernet standards designed to provide deterministic communication over standard Ethernet networks. It offers capabilities like time synchronization, bounded latency, and traffic shaping, making it suitable for mixed-criticality systems requiring real-time performance.113 TSN can support high bandwidth and is gaining traction in automotive and industrial automation, with relevance to aerospace applications.
-
Data Distribution Service (DDS): DDS is an open standard middleware protocol from the Object Management Group (OMG) that provides a data-centric publish-subscribe communication model. It is widely used in distributed real-time systems, including robotics, aerospace, and defense, due to its scalability, fault tolerance, and quality-of-service (QoS) configurability.
-
Other Bus Technologies: While traditional aerospace buses like MIL-STD-1553 or ARINC 429 are highly reliable, they may lack the bandwidth for high-rate sensor data (e.g., from imaging LWRs or multiple high-speed photodetectors). Controller Area Network (CAN) bus is common in vehicles but is also bandwidth-limited for this type of application.113 High-speed serial links (e.g., PCIe, Ethernet-based point-to-point) might be used for specific high-throughput connections between co-located processors and peripherals.
-
-
Architecture Considerations: The data bus architecture must support synchronized data exchange for effective sensor fusion (e.g., combining LWR AoA with IMU data for FSM control) and coordinated actuation (e.g., timing mirror deployment with UAV maneuver completion). Proactive routing protocols in UAV networks aim to minimize latency 114, and similar principles apply to the internal data network.
TSN or DDS, or a combination thereof, appear to be strong candidates for the primary data backbone of the DTDR system. They are specifically designed to handle the real-time, reliable, and high-volume data flows characteristic of such a complex, time-critical application. Additionally, while 118 discusses the use of Software-Defined Radio (SDR) for enhancing Physical Layer (PHY) security in UAV external communications, the principle of ensuring the integrity and authenticity of critical control signals on the internal data bus is also a pertinent consideration, especially against sophisticated electronic warfare (EW) threats that might attempt to inject malicious data or disrupt internal communications.
C. Synchronized Multi-Subsystem Control Logic for Threat Response
The core intelligence of the DTDR system resides in the integrated control logic that orchestrates the entire threat response sequence. This "brain" must be highly responsive and deterministic.
-
Event-Driven Architecture: The sequence is typically triggered by a confirmed laser threat event generated by the LWR and AI-based threat assessment subsystem.
-
State Machine Logic: A hierarchical state machine is a suitable paradigm for managing the discrete phases of the DTDR sequence:
-
IDLE/MONITORING: LWR active, system awaiting threat.
-
DETECT_CONFIRM: Initial laser detection, hit confirmation processing.
-
THREAT_VALIDATED: Confirmed threat, AoA determined.
-
AIM_TURN_INITIATE: Command UAV to execute rapid yaw maneuver towards AoA.
-
MIRROR_DEPLOY_COMMAND: Command mirror deployment (timing relative to turn is critical).
-
REFLECT_COARSE_AIM: UAV approaching target yaw, mirrors deploying/deployed.
-
REFLECT_FINE_TUNE: FSM active, stabilizing reflected beam on source using refined AoA/tracking.
-
ASSESS_EFFECTIVENESS: Monitor incoming laser for changes indicating successful counter.
-
DISENGAGE/RESET: Threat neutralized or timed out; stow mirrors, return to normal flight. This approach is similar to the state machine logic described for autonomous UAV landing 115, which also involves sequential actions based on sensor inputs and system state.
-
-
Synchronization: Tight synchronization between subsystems is crucial. This can be achieved through RTOS services (e.g., semaphores, event flags, message queues) and potentially a common, high-precision time source distributed across the processing nodes (e.g., GPS-derived for coarse synchronization, or a high-frequency internal system clock for fine-grained timing).
-
Failsafe Modes and Error Handling: Robust error handling and predefined failsafe modes are critical for system safety and reliability. The control logic must be ableto detect and respond to subsystem failures or unexpected events. For example:
-
If a mirror fails to deploy correctly, the system should abort the reflection attempt and potentially execute an alternative evasive maneuver.
-
If the UAV loses attitude stability during the aggressive turn, the priority must shift to regaining stable flight.
-
If the LWR provides conflicting or unreliable data, the system might inhibit the countermeasure or rely on a degraded mode of operation.
-
-
Degraded Mode Operation: The system should, where possible, be designed to operate with degraded information. If a primary high-precision AoA sensor is damaged or jammed, the system might attempt a "best effort" reflection using data from a secondary, less precise sensor or based on the last known good data, rather than completely disengaging.
| Platform Type | Key Specs (Representative) | Power Consumption (Typical, W) | Interfacing Capabilities | Pros for DTDR System | Cons for DTDR System | Relevant Sources |
|---|---|---|---|---|---|---|
| High-End SoC (e.g., NVIDIA Jetson AGX Orin) | Multi-core ARM CPU, High-Core GPU (e.g., Ampere), NVDLA, 32-64GB RAM, >200 AI TOPS | 15 - 75+ | PCIe, Ethernet, MIPI CSI, CAN, SPI, I2C, UART, GPIOs | Highest AI performance, ample CPU/GPU resources for complex sensor fusion and control, good software ecosystem. | Higher SWaP, higher cost, potentially overkill for some dedicated tasks. | 47 |
| Mid-Range SoC (e.g., NVIDIA Jetson Xavier NX/Orin Nano) | Fewer ARM CPU Cores, Moderate GPU (e.g., Volta/Ampere), NVDLA, 8-16GB RAM, 20-100 AI TOPS | 10 - 25 | Similar to High-End SoC, fewer lanes/ports | Good balance of AI performance and SWaP, suitable for many AI-driven UAV applications. | May be insufficient for extremely demanding, concurrent AI and signal processing loads. | 47 |
| FPGA (e.g., Xilinx Zynq UltraScale+ MPSoC) | ARM Cores + Programmable Logic (e.g., K_LEs to M_LEs), DSP slices, BRAM | 5 - 30+ (FPGA dependent) | High-speed transceivers, custom I/O, Ethernet, PCIe, AXI bus | Extremely low latency for signal processing/control loops, hardware parallelism, reconfigurable, can integrate CPU. | More complex development (HDL), higher NRE cost for complex designs, AI inference less straightforward than GPUs. | |
| Dedicated AI Accelerator + MCU | Specialized AI chip (e.g., Google Coral, Intel Movidius) + High-performance MCU (e.g., Cortex-M7/R5) | 2 - 10 (Accelerator), 0.1-1 (MCU) | USB, PCIe (Accelerator), SPI, I2C, CAN, Ethernet (MCU) | Very power-efficient AI inference, MCU for real-time control. | Limited flexibility of AI accelerator, MCU has less processing power than SoC CPU, data transfer bottlenecks. | |
| High-Performance MCU (e.g., STM32H7, TI C2000) | ARM Cortex-M7/R5, DSP extensions, FPU, High Clock Speed | 0.1 - 2 | SPI, I2C, UART, CAN, Ethernet, ADC/DAC, Timers | Excellent for hard real-time control, low power, deterministic, good peripheral set for sensor/actuator interface. | Limited processing power for complex AI or high-level sensor fusion. |
VII. System Implementation: Build Instructions and Considerations
This section provides conceptual guidelines for sourcing components, assembling the system, and calibrating its key subsystems. Practical implementation will require detailed engineering design tailored to a specific UAV platform and threat environment.
A. Component Sourcing and Selection Guidelines
The selection of components is a critical phase, balancing performance requirements with SWaP-C constraints. A mix of Commercial Off-The-Shelf (COTS) components and custom-developed elements will likely be necessary.
-
Laser Warning Receiver (LWR):
-
COTS Options: For rapid prototyping or as a baseline, existing LWRs like the Torrey Pines Logic D5™ 15 (known for fast detection and segmented AoA) or modules from companies like Excelitas (e.g., EXACTD series for precision AoA 9) could be considered.
-
Custom Development: To achieve the full suite of desired capabilities (wide spectral coverage, high dynamic range, advanced signal processing for pulse analysis and AI-based classification, integrated hit confirmation), custom LWR development or significant modification of existing modules will likely be required. This involves selecting appropriate photodetectors (APDs, PINs, imaging sensors based on Table II.A.1), designing custom optics, front-end electronics, and implementing the signal processing algorithms on suitable embedded hardware (FPGA/DSP).
-
-
UAV Platform:
-
Airframe: A highly agile quadcopter configuration is preferred. Lightweight, rigid carbon fiber construction is standard.
-
Propulsion System: High-KV brushless DC motors, responsive Electronic Speed Controllers (ESCs) capable of handling rapid throttle changes and potentially regenerative braking, and propellers optimized for agility (potentially including options for bidirectional thrust 59).
-
Battery: High-discharge rate Lithium Polymer (LiPo) or similar battery technology to supply peak power demands during aggressive maneuvers and system operation.
-
Flight Controller: A high-performance flight controller capable of running advanced attitude control algorithms (Section III.C) and interfacing with the central processing unit. Options include Pixhawk variants, or custom solutions based on MCUs like STM32.
-
-
Mirrors:
-
Substrate: Based on the analysis in Table IV.A.1, SiC is a strong candidate for its thermal and mechanical properties.81 Lightweighted aluminum could be an alternative if thermal management is addressed.82
-
Coating: Dielectric multilayer coatings optimized for anticipated threat laser wavelengths (e.g., 1064 nm, 532 nm, or broader bands if necessary) are preferred for high reflectivity and LIDT (Table IV.A.2).87
-
Fabrication: Custom fabrication by specialized optics manufacturers will be required.
-
-
Mirror Deployment Mechanisms:
-
Actuators: Selected based on the evaluation in Table IV.B.1, prioritizing speed and reliability (e.g., pre-loaded springs with fast triggers like NEPs or fast SMAs, or direct drive with fast voice coils).
-
Mechanical Components: Custom-designed hinges, linkages, and locking mechanisms using lightweight, high-strength materials (e.g., aerospace-grade aluminum alloys, titanium, composites). Precision machining is essential.
-
-
Fast Steering Mirrors (FSMs):
-
Onboard Processors:
-
Selected based on the evaluation in Table VI.A.1, considering the computational load of AI algorithms, sensor fusion, flight control, and real-time signal processing (e.g., NVIDIA Jetson, Xilinx Zynq, dedicated MCUs/FPGAs).
-
-
Sensors (beyond LWR):
-
IMU: High-quality, temperature-compensated IMU for accurate attitude estimation.
-
Hit Confirmation Sensors: Miniature thermal cameras or sensor arrays, photodiodes for monitoring drone camera dazzling.
-
GPS/GNSS: For navigation and potentially for time synchronization.
-
B. Step-by-Step Assembly and Integration (Conceptual)
The assembly and integration process requires meticulous attention to mechanical alignment, electrical connections, data interfaces, and structural integrity.
-
Airframe Preparation: Modify or design the UAV airframe to accommodate all subsystems, ensuring structural soundness, appropriate mounting points, and considerations for center of gravity.
-
LWR Sensor Head Mounting: Strategically mount LWR sensor heads/apertures to achieve the required panoramic FoV with minimal obstruction from the airframe or propellers. Ensure rigid mounting to prevent vibration-induced noise.
-
Mirror Deployment Mechanism Integration:
-
Integrate the deployment actuators, hinges, and locking mechanisms into the UAV frame. Ensure that the stowed mirrors are protected and do not impede normal flight aerodynamics.
-
Mount the optical mirrors onto the deployment arms/platforms, ensuring precise alignment relative to the deployment mechanism's kinematics.
-
-
FSM Integration (if used): Mount the FSMs in the optical path, typically to receive the beam from the main deployed mirror and provide fine angular correction. Ensure rigid mounting and precise alignment with the main mirror.
-
Processing Unit Installation: Install onboard computers (SoCs, FPGAs, MCUs) in locations that provide adequate cooling, EMI shielding, and access for programming/debugging.
-
Power Distribution: Design and implement a power distribution system capable of supplying clean, regulated power to all subsystems, considering peak load demands. Use appropriate wiring gauges and connectors.
-
Data Bus Wiring: Route data communication lines (e.g., Ethernet for TSN/DDS, SPI, I2C, CAN) between sensors, processors, and actuators. Ensure proper shielding and cable management to minimize EMI and signal integrity issues.
-
Software Installation and Configuration: Install RTOS, drivers, middleware (DDS/TSN stacks), AI models, flight control software, and application-specific control logic onto the respective processing units.
-
Initial Bench Testing: Test each subsystem individually before full integration to verify functionality and basic performance.
A critical consideration during integration is Electromagnetic Compatibility/Interference (EMC/EMI). The UAV environment is electromagnetically noisy due to high-power motors, ESCs, radio transmitters, and high-speed digital processors. Sensitive analog front-ends of the LWR and other sensors can be susceptible to this interference. Proper grounding strategies, shielding of sensitive components and cables, and careful physical layout are essential to prevent self-jamming and ensure the reliable operation of all subsystems.
C. Calibration Procedures for Key Subsystems
Accurate calibration is fundamental to the performance and reliability of the DTDR system.
-
LWR Calibration:
-
AoA Calibration: Expose the LWR to calibrated laser sources at known angles of arrival across its entire field of view. Generate a lookup table or calibration function to correct any systematic AoA errors. This should be done for different wavelengths if the AoA determination is wavelength-dependent.
-
Wavelength Calibration: If the LWR includes wavelength determination capabilities (e.g., via filtered detectors or a spectrometer), calibrate its response against sources of known wavelengths.
-
Intensity Calibration: Calibrate the LWR's intensity measurement across its dynamic range using calibrated laser sources and variable attenuators.
-
Pulse Parameter Extraction Calibration: Verify the accuracy of PRF, pulse width, and other temporal parameter measurements using a pulsed laser source with precisely controllable pulse characteristics.
-
-
Flight Control System Calibration:
-
IMU Calibration: Perform standard multi-position static and dynamic calibrations to determine accelerometer and gyroscope biases, scale factors, and axis misalignments. Temperature compensation calibration is also crucial.
-
Motor/ESC Calibration: Calibrate ESC throttle ranges and verify motor thrust characteristics.
-
Attitude Control Loop Tuning: Tune PID gains (or other controller parameters) for the aggressive yaw maneuver, optimizing for speed, precision, and stability. This may involve iterative bench testing, simulation, and ultimately flight testing.
-
-
Mirror Deployment Mechanism Calibration:
-
Deployed Angle Verification: Precisely measure the angle of the mirrors when fully deployed and locked. Adjust mechanical stops or control parameters to achieve the design angle with tight tolerance.
-
Locking Mechanism Engagement: Verify reliable and consistent engagement of the locking mechanism across multiple deployment cycles and under simulated vibration/load conditions.
-
Deployment Time Measurement: Measure the time taken from actuation command to fully deployed and locked state.
-
-
FSM Calibration:
-
Angular Response Calibration: Map the FSM's angular tilt (tip and tilt axes) to actuator input commands. Determine scale factors, linearity, and maximum angular range.
-
Bandwidth/Frequency Response: Characterize the FSM's dynamic response to determine its operational bandwidth and resonant frequencies.
-
Alignment: Precisely align the FSM's optical axis with the main deployed mirror and the overall system reference frame.
-
-
End-to-End System Calibration (Boresighting):
-
After individual subsystem calibration, perform an end-to-end boresight calibration. This involves directing a known laser source at the drone, allowing the LWR to detect it, and then verifying that the reflected beam (controlled by the FSM, if active) is accurately directed back to a target sensor co-located with the source laser. This critical step aligns all coordinate frames and compensates for any residual system-level misalignments.
-
VIII. Testing and Validation Methodology
Rigorous testing and validation are essential to ensure the DTDR system meets its performance requirements and operates reliably. This should proceed in a phased approach, from laboratory testing of individual components to full system flight trials.
-
A. Laboratory and Benchtop Testing:
-
LWR Performance: Test LWR sensitivity, AoA accuracy, wavelength identification, intensity measurement range, and pulse parameter extraction capabilities using calibrated laser sources with varying characteristics (wavelength, power, pulse width, PRF, PIM codes). Evaluate Pd and FAR against simulated threat and non-threat signals. Test hit confirmation logic with simulated thermal/dazzling inputs.
-
Mirror Deployment: Cycle the deployment and locking mechanisms repeatedly to assess speed, precision, repeatability, and durability. Test under simulated vibration and G-loads. Measure deployment times accurately (e.g., high-speed camera).
-
FSM Performance: Characterize FSM bandwidth, step response, pointing accuracy, and stability. Test its ability to compensate for simulated UAV jitter profiles.
-
UAV Agility (Ground/Tethered Tests): Test the flight controller's ability to execute rapid yaw maneuvers on a ground-based test rig or a short tether, measuring angular rates and accelerations. This allows tuning of control parameters in a safe environment before free flight.
-
Integrated Subsystem Tests: Test data flow and synchronization between linked subsystems (e.g., LWR output triggering simulated drone maneuver and mirror deployment).
-
-
B. Controlled Environment Flight Testing (Indoor/Outdoor):
-
Basic Flight Stability with Stowed System: Verify normal flight characteristics with the DTDR system components integrated but inactive.
-
Rapid Maneuver Execution: Conduct free-flight tests of the 180-degree yaw maneuver without mirror deployment, carefully measuring maneuver time, pointing accuracy, and stability.
-
Mirror Deployment in Flight: Test mirror deployment during hover and at various forward speeds to assess aerodynamic impact and control system response.
-
Initial Reflection Tests (Low Power): Use a low-power, eye-safe laser source to simulate an attack. Test the full DTDR sequence: detection, turn, deployment, and reflection. Use a sensor target co-located with the laser source to measure the accuracy of the reflected beam.
-
-
C. Open-Air Testing Against Simulated HEL Threats:
-
Utilize higher-power (but still controlled and eye-safe where humans are present, or in restricted test ranges) laser sources that emulate the characteristics of actual HEL threats.
-
Test the system's ability to detect, classify, and respond to these more realistic threat signatures.
-
Evaluate pointing accuracy and stability of the reflected beam over tactically relevant distances.
-
Assess the impact of atmospheric conditions (turbulence, obscurants) on system performance.
-
Conduct tests against moving simulated laser sources to evaluate tracking and engagement of dynamic threats.
-
-
D. Performance Metrics for Validation:
-
Quantitatively measure all KPPs defined in Section I.C (Overall Reaction Time, Pd/FAR, Reorientation Agility, Mirror Deployment Speed, Reflection Accuracy, etc.).
-
Record detailed telemetry from all subsystems during tests (LWR data, IMU data, flight controller commands, mirror actuator status, FSM pointing data).
-
Use high-speed cameras and external tracking systems (e.g., Vicon, OptiTrack) to independently verify UAV motion and mirror deployment.
-
IX. Safety Considerations
The development and testing of a system involving high-power lasers and agile UAVs necessitate stringent safety protocols.
-
Laser Safety:
-
Adherence to all applicable laser safety standards (e.g., ANSI Z136 series, IEC 60825).
-
Use of appropriate laser safety eyewear rated for the wavelengths and power levels involved during all testing.116
-
Establishment of controlled laser test ranges with restricted access, proper beam stops, and interlock systems.
-
Procedures for handling and operating high-power lasers.
-
Risk assessment for accidental reflection or misdirection of the laser beam.
-
-
UAV Flight Safety:
-
Compliance with all relevant aviation regulations for UAV operation.
-
Pre-flight checks and maintenance procedures.
-
Operation in designated airspace, clear of unauthorized personnel and obstacles.
-
Use of geofencing and emergency flight termination systems.
-
Contingency plans for system malfunctions or loss of control.
-
-
System-Specific Hazards:
-
Potential for unexpected UAV motion during aggressive maneuvers or due to aerodynamic disturbances from mirror deployment. Phased testing in increasingly complex environments is crucial.
-
Safe handling of rapid deployment mechanisms (e.g., stored spring energy, pyrotechnic triggers if used).
-
Ensuring the reflected laser beam is directed only at the intended target source and does not pose a collateral hazard.
-
X. Conclusions and Future Directions
The design of a drone-based active laser reflection countermeasure system, as outlined, presents a formidable but potentially achievable engineering challenge. The core DTDR (Detect, Turn, Deploy, Reflect) concept relies on the rapid and precise synchronization of multiple advanced subsystems, each pushing the boundaries of current technology in terms of speed, accuracy, and SWaP constraints.
Key Findings and Feasibility Assessment:
-
Detection and Characterization: Modern LWR technology, incorporating sensitive photodetectors (APDs, imaging sensors), advanced signal processing for pulse parameter extraction (PRF, pulse width, PIM codes), and AI-driven threat classification, can provide the necessary inputs for threat validation and AoA determination.2 Hit confirmation through sensor fusion (e.g., thermal, optical dazzling) is critical for minimizing false alarms.1 The primary challenge lies in achieving the required AoA accuracy and classification speed within a very tight time budget.
-
UAV Agility: Achieving a 180-degree yaw maneuver in under 1-2 seconds is feasible with highly agile quadcopter platforms (e.g., racing drones or custom designs) employing advanced flight control algorithms like INDI or fixed-time SMC.54 However, precise data on maximum unconstrained angular accelerations for such maneuvers needs platform-specific experimental validation. Aerodynamic disturbances during the maneuver and especially during mirror deployment must be robustly handled by the flight controller.
-
Mirror Subsystem: Lightweight, thermally stable mirror substrates (e.g., SiC) with high-LIDT dielectric coatings can meet the optical performance requirements.81 Ultra-fast deployment (< 50ms, ideally < 20ms) is a significant challenge, likely requiring innovative mechanisms such as pre-loaded springs with extremely fast triggers (e.g., NEPs, fast SMAs, or voice coils) and precision locking systems.97
-
Reflection Aiming and Precision: Due to platform jitter, control inaccuracies, and atmospheric effects, direct uncompensated reflection is unlikely to be sufficiently accurate. Miniature Fast Steering Mirrors (FSMs) are essential for fine-pointing the reflected beam, compensating for residual errors and stabilizing the beam on the source.23 A comprehensive pointing error budget is crucial to guide design tolerances. The control of the FSM, tightly coupled with the LWR and IMU, is a critical element.
-
System Integration and Control: A high-performance, distributed onboard processing architecture using SoCs, FPGAs, and MCUs, managed by an RTOS and communicating via a low-latency data bus (e.g., TSN or DDS), is necessary to orchestrate the complex, time-critical DTDR sequence.47
The overall concept appears technically plausible, but its successful realization depends on pushing the performance envelope of several key technologies simultaneously and integrating them into a highly synchronized system. The most significant challenges lie in achieving the extreme speed requirements for each step of the DTDR sequence while maintaining precision and robustness within UAV SWaP constraints.
Future Research and Development Directions:
-
Advanced LWR Development: Focus on miniaturized LWRs with enhanced AoA accuracy (<0.1°), faster response times (<10ms), improved PIM code deinterleaving, and more sophisticated AI-based real-time classification of novel and agile laser threats.
-
Hyper-Agile UAV Platforms: Research into novel UAV designs and propulsion systems (e.g., leveraging bidirectional thrust) specifically optimized for extreme angular acceleration and rapid, large-angle attitude changes with minimal translational disturbance.
-
Millisecond-Scale Deployment Mechanisms: Development and validation of ultra-fast (<10-20ms), reliable, and precise deployment and locking mechanisms for optical elements, potentially using advanced smart materials or hybrid actuation schemes.
-
Robust FSM Control in Dynamic Environments: Advanced FSM control algorithms that can effectively use fused sensor data (LWR AoA, IMU, potentially dedicated trackers) for precise laser retro-reflection from highly dynamic and vibrating UAV platforms, including robust compensation for atmospheric turbulence.
-
Reflected Beam Hit Assessment: Techniques for the drone to autonomously assess the effectiveness of its reflected beam on the target laser source, enabling closed-loop correction or confirmation of neutralization.
-
Integrated Simulation and Hardware-in-the-Loop (HITL) Testing: Development of high-fidelity simulation environments that can model the entire engagement, including HEL propagation, LWR response, UAV dynamics, mirror deployment, FSM control, and aerodynamic effects, for comprehensive system design, tuning, and validation using HITL techniques.
-
SWaP Optimization and Miniaturization: Continuous efforts to reduce the size, weight, and power consumption of all components to enhance UAV endurance and allow deployment on smaller platforms.
-
Counter-Countermeasures: As this technology matures, adversaries will develop countermeasures. Research into making the DTDR system more resilient to jamming, deception, or attacks against its own sensors will be necessary.
In conclusion, the proposed drone-based active laser reflection system represents a sophisticated approach to countering HEL threats. While significant engineering challenges exist, ongoing advancements in sensor technology, UAV agility, rapid actuation, and AI-driven control provide a pathway towards realizing such a capability. Success will depend on a rigorous, systems-engineering approach, focused on achieving extreme speed and precision across all elements of the DTDR sequence.
Works cited
- Assessing laser dazzling effects on UAV cameras and collision avoidance in laboratory and field settings - SPIE Digital Library, accessed May 26, 2025, https://www.spiedigitallibrary.org/conference-proceedings-of-spie/13201/3031630/Assessing-laser-dazzling-effects-on-UAV-cameras-and-collision-avoidance/10.1117/12.3031630.full
- Laser Warning Receivers - Global Strategic Business Report, accessed May 26, 2025, https://www.researchandmarkets.com/reports/6089430/laser-warning-receivers-global-strategic
- NPS Develops AI Solution to Automate Drone Defense with High Energy Lasers, accessed May 26, 2025, https://nps.edu/-/nps-develops-ai-solution-to-automate-drone-defense-with-high-energy-lasers
- Drones are fighting back against laser attacks - 311 Institute, accessed May 26, 2025, https://www.311institute.com/drones-are-fighting-back-against-laser-attacks/
- AI Automates Drone Defense With High Energy Lasers - Mobility Engineering Technology, accessed May 26, 2025, https://www.mobilityengineeringtech.com/component/content/article/52999-ai-automates-drone-defense-with-high-energy-lasers
- Laser warning receiver - Wikipedia, accessed May 26, 2025, https://en.wikipedia.org/wiki/Laser_warning_receiver
- Laser warning technology: an overview of principles, developments ..., accessed May 26, 2025, https://proceedings.spiedigitallibrary.org/proceedings/Download?urlId=10.1117%2F12.3052719&downloadType=proceedings%20article&isResultClick=True
- Analysis of new laser warning technologies to propose a new optical subsystem, accessed May 26, 2025, https://www.researchgate.net/publication/327688476_Analysis_of_new_laser_warning_technologies_to_propose_a_new_optical_subsystem
- Laser Warning Detectors | Excelitas, accessed May 26, 2025, https://www.excelitas.com/product-category/laser-warning-detectors
- Avalanche Photodiodes - Detectors - Laser Components, accessed May 26, 2025, https://www.lasercomponents.com/us/products/detectors/avalanche-photodiodes/
- 31st international congress on high-speed imaging and photonics | 7-10 november 2016 - SPIE Digital Library, accessed May 26, 2025, https://www.spiedigitallibrary.org/conference-proceedings-of-spie/10328
- A Novel Pulse Measurement System by Using Laser Triangulation and a CMOS Image Sensor - MDPI, accessed May 26, 2025, https://www.mdpi.com/1424-8220/7/12/3366
- Drone Detection and Tracking in Real-Time by Fusion of Different Sensing Modalities, accessed May 26, 2025, https://www.mdpi.com/2504-446X/6/11/317
- Airborne Laser Systems Testing and Analysis - NATO Science & Technology Organization, accessed May 26, 2025, https://www.sto.nato.int/publications/STO%20Technical%20Reports/RTO-AG-300-V26/$$AG-300-V26-ALL.pdf
- D5™ Personal/Drone Hemispheric Laser Warning - Torrey Pines ..., accessed May 26, 2025, https://tplogic.com/laser-detection/d5/
- labpartnering.org, accessed May 26, 2025, https://labpartnering.org/patents/US7683310#:~:text=A%20signal%20processor%20receives%20the,at%20least%20one%20optical%20wedge.
- Laser warning receiver to identify the wavelength and angle of ..., accessed May 26, 2025, https://www.osti.gov/biblio/1014461
- www.nielit.gov.in, accessed May 26, 2025, https://www.nielit.gov.in/sites/default/files/Aurangabad/Detection%20of%20angle-of-arrival%20of%20the%20Laser%20beam%20using%20a%20cylindrical%20lens%20and%20Gaussian%20beam%20curve%20fitting.pdf
- (SBIR) Navy - Shipboard Laser Detection, accessed May 26, 2025, https://navysbir.us/n07_1/n071-100.htm
- Simulation of laser beam propagation over land and sea using phase screens - A comparison with experimental data - ResearchGate, accessed May 26, 2025, https://www.researchgate.net/publication/228544372_Simulation_of_laser_beam_propagation_over_land_and_sea_using_phase_screens_-_A_comparison_with_experimental_data
- Laser beam propagation in atmospheric turbulence, accessed May 26, 2025, https://www.ias.ac.in/public/Volumes/sadh/002/02/0179-0195.pdf
- Adaptive Beam Divergence Control to Mitigate Scintillation Effect Caused by Pointing Error in Vertical FSO Transmissions - ResearchGate, accessed May 26, 2025, https://www.researchgate.net/publication/371062705_Adaptive_Beam_Divergence_Control_to_Mitigate_Scintillation_Effect_Caused_by_Pointing_Error_in_Vertical_FSO_Transmissions
- Design of Novel Laser Crosslink Systems Using Nanosatellites in Formation Flying: The VISION - MDPI, accessed May 26, 2025, https://www.mdpi.com/2226-4310/9/8/423
- Investigation on the UAV-To-Satellite Optical Communication Systems - ResearchGate, accessed May 26, 2025, https://www.researchgate.net/publication/327000758_Investigation_on_the_UAV-To-Satellite_Optical_Communication_Systems
- Laser Power Sensor - Ophir, accessed May 26, 2025, https://www.ophiropt.com/en/c/laser-power-sensors
- High-speed wide dynamic range linear mode time-of-flight receiver based on zero-crossing timing detection - SPIE Digital Library, accessed May 26, 2025, https://www.spiedigitallibrary.org/journals/optical-engineering/volume-59/issue-10/104102/High-speed-wide-dynamic-range-linear-mode-time-of-flight/10.1117/1.OE.59.10.104102.full
- 3.4 Pulser and Receiver Operation | Evident - Olympus Scientific Solutions, accessed May 26, 2025, https://ims.evidentscientific.com/en/learn/ndt-tutorials/flaw-detection/pulser-and-receiver
- Abstract Summaries - SPIE, accessed May 26, 2025, https://spie.org/documents/ConferencesExhibitions/PA10-Abstracts.pdf
- (PDF) Quantitative assessment of laser-dazzling effects on a CCD-camera through pattern-recognition-algorithms performance measurements - ResearchGate, accessed May 26, 2025, https://www.researchgate.net/publication/229001892_Quantitative_assessment_of_laser-dazzling_effects_on_a_CCD-camera_through_pattern-recognition-algorithms_performance_measurements
- Pulsed Lasers - Thorlabs, accessed May 26, 2025, https://www.thorlabs.com/images/tabimages/Laser_Pulses_Power_Energy_Equations.pdf
- The Real-Time Temporal and Spatial Diagnostics of Ultashort High-Power Laser Pulses using an All-Reflective Single-Shot Autocorrelator - ResearchGate, accessed May 26, 2025, https://www.researchgate.net/publication/267340874_The_Real-Time_Temporal_and_Spatial_Diagnostics_of_Ultashort_High-Power_Laser_Pulses_using_an_All-Reflective_Single-Shot_Autocorrelator
- Temporal Characterization of Laser Pulses Using an Air‐Based Knife‐Edge Technique, accessed May 26, 2025, https://www.researchgate.net/publication/381772711_Temporal_Characterization_of_Laser_Pulses_Using_an_Air-Based_Knife-Edge_Technique
- electronics.leonardo.com, accessed May 26, 2025, https://electronics.leonardo.com/documents/16277707/18388119/Copia_di_RALM02_v2_LQ_mm08402_.pdf?t=1538987453110
- (PDF) Suitable Combination of Direct Intensity Modulation and ..., accessed May 26, 2025, https://www.researchgate.net/publication/329332052_Suitable_Combination_of_Direct_Intensity_Modulation_and_Spreading_Sequence_for_LIDAR_with_Pulse_Coding
- Airborne Radar Staggered PRF Coherent Processing Method for Down-Looking Target Detection - MDPI, accessed May 26, 2025, https://www.mdpi.com/2072-4292/15/13/3271
- Laser Sensors | Coherent, accessed May 26, 2025, https://www.coherent.com/laser-power-energy-measurement/laser-sensors
- Volume Table of Contents - SPIE Digital Library, accessed May 26, 2025, https://www.spiedigitallibrary.org/conference-proceedings-of-SPIE/13104.toc
- Volume Table of Contents - SPIE Digital Library, accessed May 26, 2025, https://www.spiedigitallibrary.org/conference-proceedings-of-spie/13639.toc
- (PDF) A Survey on Detection, Classification, and Tracking of Aerial Threats using Radar and Communications Systems - ResearchGate, accessed May 26, 2025, https://www.researchgate.net/publication/377741982_A_Survey_on_Detection_Classification_and_Tracking_of_Aerial_Threats_using_Radar_and_Communications_Systems
- Integrating Large Language Models with Internet of Things Applications - arXiv, accessed May 26, 2025, https://arxiv.org/pdf/2410.19223?
- Signature-based intrusion detection using machine learning and deep learning approaches empowered with fuzzy clustering - PubMed Central, accessed May 26, 2025, https://pmc.ncbi.nlm.nih.gov/articles/PMC11724853/
- AI in Cybersecurity: Using Machine Learning for Threat Detection and Response, accessed May 26, 2025, https://www.researchgate.net/publication/390943564_AI_in_Cybersecurity_Using_Machine_Learning_for_Threat_Detection_and_Response
- A Survey on Detection, Classification, and Tracking of UAVs using Radar and Communications Systems - arXiv, accessed May 26, 2025, https://arxiv.org/html/2402.05909v2
- Machine learning algorithms applied for drone detection and classification: benefits and challenges - Frontiers, accessed May 26, 2025, https://www.frontiersin.org/journals/communications-and-networks/articles/10.3389/frcmn.2024.1440727/full
- (PDF) Recent advances in deep learning models: a systematic literature review, accessed May 26, 2025, https://www.researchgate.net/publication/370253630_Recent_advances_in_deep_learning_models_a_systematic_literature_review
- RNN-DAS: A New Deep Learning Approach for Detection and Real-Time Monitoring of Volcano-Tectonic Events Using Distributed Acoustic Sensing - arXiv, accessed May 26, 2025, https://arxiv.org/html/2503.11622
- Ukraine's Future Vision and Current Capabilities for Waging AI-Enabled Autonomous Warfare - CSIS, accessed May 26, 2025, https://www.csis.org/analysis/ukraines-future-vision-and-current-capabilities-waging-ai-enabled-autonomous-warfare
- Advances in UAV Avionics Systems Architecture, Classification and Integration: A Comprehensive Review and Future Perspectives - arXiv, accessed May 26, 2025, https://arxiv.org/html/2501.00856v1
- A Review of Counter-UAS Technologies for Cooperative Defensive Teams of Drones - MDPI, accessed May 26, 2025, https://www.mdpi.com/2504-446X/6/3/65
- LLM Cyber Evaluations Don't Capture Real-World Risk - arXiv, accessed May 26, 2025, https://www.arxiv.org/pdf/2502.00072
- (PDF) Control-Oriented Real-Time Trajectory Planning for Heterogeneous UAV Formations, accessed May 26, 2025, https://www.researchgate.net/publication/388258453_Control-Oriented_Real-Time_Trajectory_Planning_for_Heterogeneous_UAV_Formations
- Quadrotor Helicopter Trajectory Tracking Control - Stanford AI Lab, accessed May 26, 2025, https://ai.stanford.edu/~gabeh/papers/GNC08_QuadTraj.pdf
- Attitude and position control with minimum snap trajectory planning for quadrotor UAV | Request PDF - ResearchGate, accessed May 26, 2025, https://www.researchgate.net/publication/367119749_Attitude_and_position_control_with_minimum_snap_trajectory_planning_for_quadrotor_UAV
- Accurate Tracking of Aggressive Quadrotor Trajectories Using Incremental Nonlinear Dynamic Inversion and Differential Flatness - ResearchGate, accessed May 26, 2025, https://www.researchgate.net/publication/342323860_Accurate_Tracking_of_Aggressive_Quadrotor_Trajectories_Using_Incremental_Nonlinear_Dynamic_Inversion_and_Differential_Flatness
- One Net to Rule Them All: Domain Randomization in Quadcopter Racing Across Different Platforms - arXiv, accessed May 26, 2025, https://arxiv.org/pdf/2504.21586
- arxiv.org, accessed May 26, 2025, https://arxiv.org/html/2505.13836v1
- Trajectory generation and control for precise aggressive maneuvers with quadrotors | Request PDF - ResearchGate, accessed May 26, 2025, https://www.researchgate.net/publication/229037672_Trajectory_generation_and_control_for_precise_aggressive_maneuvers_with_quadrotors
- Cable Optimization and Drag Estimation for Tether-Powered Multirotor UAVs - arXiv, accessed May 26, 2025, https://arxiv.org/html/2504.07802v1
- Coordinated Control for Robot-assisted Take-off and Landing of Flying Robots - DLR, accessed May 26, 2025, https://elib.dlr.de/147046/1/Maier-Moritz-Andreas_TUM_2020.pdf
- Improved Fixed-time Attitude Tracking Control for Quadcopter Unmanned Aerial Vehicles, accessed May 26, 2025, https://www.researchgate.net/publication/386199020_Improved_Fixed-time_Attitude_Tracking_Control_for_Quadcopter_Unmanned_Aerial_Vehicles?_tp=eyJjb250ZXh0Ijp7InBhZ2UiOiJzY2llbnRpZmljQ29udHJpYnV0aW9ucyIsInByZXZpb3VzUGFnZSI6bnVsbCwic3ViUGFnZSI6bnVsbH19
- dspace.mit.edu, accessed May 26, 2025, https://dspace.mit.edu/bitstream/handle/1721.1/133387/1809.04048.pdf?sequence=2&isAllowed=y
- (PDF) Time optimal attitude control for a rigid body - ResearchGate, accessed May 26, 2025, https://www.researchgate.net/publication/224323247_Time_optimal_attitude_control_for_a_rigid_body
- UNIVERSITY OF CALIFORNIA Los Angeles Control Implementation of Dynamic Locomotion on Compliant, Underactuated, Force-Controlled - eScholarship, accessed May 26, 2025, https://escholarship.org/content/qt4kg40479/qt4kg40479_noSplash_2d7325472259719e80535b07e34d8107.pdf
- 563870540.pdf - CORE, accessed May 26, 2025, https://core.ac.uk/download/563870540.pdf
- Flight Control of a Millimeter-Scale Flapping-Wing Robot - Harvard DASH, accessed May 26, 2025, https://dash.harvard.edu/server/api/core/bitstreams/d98f4f79-2924-4100-93b2-1a42b062a69d/content
- ICRA 2025 Program | Wednesday May 21, 2025, accessed May 26, 2025, https://ras.papercept.net/conferences/conferences/ICRA25/program/ICRA25_ContentListWeb_2.html
- Time-Optimal Control via Heaviside Step-Function Approximation - arXiv, accessed May 26, 2025, https://arxiv.org/pdf/2303.04516
- Data-Efficient Deep Reinforcement Learning for Attitude Control of Fixed-Wing UAVs: Field Experiments - Tor Arne Johansen, accessed May 26, 2025, https://torarnj.folk.ntnu.no/DRL_UAV.pdf
- Design and Basic Aerodynamic Analysis of a Drone-Suspended Transport Container for Safe Biological Sample Transport - MDPI, accessed May 26, 2025, https://www.mdpi.com/2411-9660/9/1/20
- Aerodynamics and Sensing Analysis for Efficient Drone-Based Parcel Delivery - arXiv, accessed May 26, 2025, https://arxiv.org/html/2410.20584v1
- Computational fluid dynamics analysis of aerodynamic characteristics in long-endurance unmanned aerial vehicles - PMC - PubMed Central, accessed May 26, 2025, https://pmc.ncbi.nlm.nih.gov/articles/PMC11489356/
- Investigating the aerodynamic performance of an UAV - DiVA portal, accessed May 26, 2025, https://www.diva-portal.org/smash/get/diva2:1607611/FULLTEXT01.pdf
- 40th ASME/AIAA Online Regional Symposium, Oklahoma State University, April 3, 2021 - Collection Device for Dolphin Hormones in Blowhole Jet Flow Field Eric Abele1,*, Kerrick Ray2, and Dr. Jamey Jacob3, accessed May 26, 2025, https://ceat.okstate.edu/mae/site_files/docs/research/symposium-files/combined-abstracts-file.pdf
- On Nonlinear and Optimization-based Control of Fixed-Wing Unmanned Aerial Vehicles - Tor Arne Johansen - NTNU, accessed May 26, 2025, https://torarnj.folk.ntnu.no/thesis_final_DR_wfrontpage.pdf
- CFD analysis of the aerodynamic effects on the stability of the flight of a quadcopter UAV in the proximity of walls and ground | Request PDF - ResearchGate, accessed May 26, 2025, https://www.researchgate.net/publication/345962240_CFD_analysis_of_the_aerodynamic_effects_on_the_stability_of_the_flight_of_a_quadcopter_UAV_in_the_proximity_of_walls_and_ground
- Aircraft Dynamics, Wind Tunnel Testing and CFD Flow Visualization of Two Linked UAVs Flying at Close Proximity - ResearchGate, accessed May 26, 2025, https://www.researchgate.net/publication/252187847_Aircraft_Dynamics_Wind_Tunnel_Testing_and_CFD_Flow_Visualization_of_Two_Linked_UAVs_Flying_at_Close_Proximity
- Aerodynamic Analysis by CFD Simulation VS Wind-Tunnel Test to reduce Drag of UAV Aircraft - The International Undergraduate Research Conference, accessed May 26, 2025, https://iugrc.journals.ekb.eg/article_245412.html
- Computational modeling of the aerodynamic characteristics and flight mechanics and control of an unmanned aerial vehicle - SciSpace, accessed May 26, 2025, https://scispace.com/pdf/computational-modeling-of-the-aerodynamic-characteristics-4gq5t103q1.pdf
- Ground Effect on a Landing Platform for an Unmanned Aerodynamic System, accessed May 26, 2025, https://openaccess-api.cms-conferences.org/articles/download/978-1-958651-69-8_7
- A fast and automated approach for urban CFD simulations: integration with meteorological predictions and its application to drone flights - arXiv, accessed May 26, 2025, https://arxiv.org/html/2505.14703v1
- Foam core enables stiff lightweight mirrors | SPIE, the international society for optics and photonics, accessed May 26, 2025, https://www.spie.org/news/0258-foam-core-enables-stiff-lightweight-mirrors
- Aluminum Mirrors: Substrate Materials for CO2 Laser Optics, accessed May 26, 2025, https://www.eoc-inc.com/co2-laser-optics-reflective-mirrors/aluminum-mirrors-substrate-materials-for-co2-laser-optics/
- Laser Mirror Substrates | Edmund Optics, accessed May 26, 2025, https://www.edmundoptics.com/c/laser-mirror-substrates/1219/
- ultra-lightweight mirror program: Topics by Science.gov, accessed May 26, 2025, https://www.science.gov/topicpages/u/ultra-lightweight+mirror+program
- Flexible Surface Reflector Antenna for Small Satellites - MDPI, accessed May 26, 2025, https://www.mdpi.com/2226-4310/12/5/414
- Flexible Surface Reflector Antenna for Small Satellites - Preprints.org, accessed May 26, 2025, https://www.preprints.org/manuscript/202503.0672/v1
- Technical Details of Optical Coatings - SCHOTT, accessed May 26, 2025, https://www.schott.com/en-gb/products/optical-coatings-p1000264/technical-details
- Dielectric Mirrors - Filtrop AG, accessed May 26, 2025, https://www.filtrop.com/wp-content/uploads/2021/11/Mirror_dielectric-e.pdf
- Laser Mirrors - High Reflectivity Mirrors - Notch Optics, accessed May 26, 2025, https://notchoptics.com/laser-mirrors/
- Mirror Coatings - Laser Components, accessed May 26, 2025, https://www.lasercomponents.com/fileadmin/user_upload/home/Datasheets/lc-optics/coatings/mirror_coating.pdf
- Optical Coatings - Thorlabs, accessed May 26, 2025, https://www.thorlabs.com/OpticalCoatings
- Understanding and Specifying LIDT of Laser Components - Edmund Optics, accessed May 26, 2025, https://www.edmundoptics.com/knowledge-center/application-notes/lasers/understanding-and-specifying-lidt-of-laser-components/
- Challenges of Specifying LIDT for CW Lasers | Edmund Optics, accessed May 26, 2025, https://www.edmundoptics.com/knowledge-center/application-notes/lasers/challenges-of-specifying-lidt-for-cw-lasers/
- Challenges in the development of a reliable cw-LIDT measurement routine, accessed May 26, 2025, https://opg.optica.org/abstract.cfm?uri=ome-13-6-1712
- Volume Table of Contents - SPIE Digital Library, accessed May 26, 2025, https://www.spiedigitallibrary.org/conference-proceedings-of-SPIE/13190.toc
- TECHNICAL GUIDE - IDEX Optical Technologies, accessed May 26, 2025, https://www.idexot.com/media/wysiwyg/cms-pages/pdf/Optical_Coating_and_Materials.pdf
- US10112698B2 - Deployment mechanism - Google Patents, accessed May 26, 2025, https://patents.google.com/patent/US10112698B2/en
- Fast Steering Mirror Systems - Newport, accessed May 26, 2025, https://www.newport.com/f/fast-steering-mirror-systems
- Miniaturized Fast Steering Mirror Platforms (FSM) for Laser Beam Control are Piezo-based - PI-USA.us, accessed May 26, 2025, https://www.pi-usa.us/fileadmin/user_upload/pi_us/files/press_releases/PI_Steering_Mirror_Platform_S335.pdf
- What are some Popular Micro Actuator Use Cases - Firgelli Automations, accessed May 26, 2025, https://www.firgelliauto.com/blogs/news/what-are-some-popular-micro-actuator-use-cases
- non-explosive release actuator: Topics by Science.gov, accessed May 26, 2025, https://www.science.gov/topicpages/n/non-explosive+release+actuator
- Lightweight In-Plane Actuated Deformable Mirrors for Space Telescopes - DTIC, accessed May 26, 2025, https://apps.dtic.mil/sti/tr/pdf/ADA455202.pdf
- Research on lightweight passive deployment mechanism for the secondary mirror in the deployable space telescope | Request PDF - ResearchGate, accessed May 26, 2025, https://www.researchgate.net/publication/309443924_Research_on_lightweight_passive_deployment_mechanism_for_the_secondary_mirror_in_the_deployable_space_telescope
- System Integration Design of High-Performance Piezo-Actuated Fast-Steering Mirror for Laser Beam Steering System - MDPI, accessed May 26, 2025, https://www.mdpi.com/1424-8220/24/21/6775
- Fast Steering Mirrors | ulsis, accessed May 26, 2025, https://www.ulsis.com/our-products/fast-steering-mirrors
- beam divergence – angle - RP Photonics, accessed May 26, 2025, https://www.rp-photonics.com/beam_divergence.html
- Experimental verification of fiber coupling characteristics for FSO downlinks from the International Space Station - ResearchGate, accessed May 26, 2025, https://www.researchgate.net/publication/367662411_Experimental_verification_of_fiber_coupling_characteristics_for_FSO_downlinks_from_the_International_Space_Station
- A Review–Unguided Optical Communications: Developments, Technology Evolution, and Challenges - MDPI, accessed May 26, 2025, https://www.mdpi.com/2079-9292/12/8/1922?type=check_update&version=1
- US20220321198A1 - Dynamic control of an unmanned aerial vehicle using a reconfigurable intelligent surface - Google Patents, accessed May 26, 2025, https://patents.google.com/patent/US20220321198A1/en
- A Review on IoT Deep Learning UAV Systems for Autonomous Obstacle Detection and Collision Avoidance - MDPI, accessed May 26, 2025, https://www.mdpi.com/2072-4292/11/18/2144
- Technology for Evolutionary Software Development (Technologies pour le developpement de logiciels evolutifs) - DTIC, accessed May 26, 2025, https://apps.dtic.mil/sti/tr/pdf/ADA418695.pdf
- all tracks - Embedded Online Conference, accessed May 26, 2025, https://embeddedonlineconference.com/tracks.php
- 10/04/2025 06:51 Time-sensitive autonomous architectures / Ferraro, D; Palazzi, L; Gavioli, F; Guzzinati, M; Bernardi, A; Rouxel - IRIS Unimore, accessed May 26, 2025, https://iris.unimore.it/bitstream/11380/1322726/1/TSAA__springer_.pdf
- Unmanned Aerial Vehicles (UAV) Networking Algorithms: Communication, Control, and AI-Based Approaches - MDPI, accessed May 26, 2025, https://www.mdpi.com/1999-4893/18/5/244
- Proactive Guidance for Accurate UAV Landing on a Dynamic Platform: A Visual–Inertial Approach - MDPI, accessed May 26, 2025, https://www.mdpi.com/1424-8220/22/1/404
- Simplifying Laser Alignment - Edmund Optics, accessed May 26, 2025, https://www.edmundoptics.com/knowledge-center/application-notes/lasers/simplifying-laser-alignment/
- Drones Resistant to Different Weather Conditions - Xray, accessed May 26, 2025, https://xray.greyb.com/drones/weather-resistant-drones
- (PDF) Software-Defined Radio Deployments in UAV-Driven Applications: A Comprehensive Review - ResearchGate, accessed May 26, 2025, https://www.researchgate.net/publication/381259303_Software-Defined_Radio_Deployments_in_UAV-Driven_Applications_A_Comprehensive_Review
First published . Last revised . Also on Google Docs.